Heavy-Payload AMR Wheel Selection: Material, Geometry, Heat, Wear and Service Life
A Wheel Is a Consumable Engineering Interface, Not a Catalog Accessory
A heavy-payload mobile robot does not interact with the factory through its payload plate, motor rating or navigation map. It interacts through a small number of wheel contact patches. Those patches carry the configured mass, transmit propulsion and braking forces, absorb joints and debris, generate rolling loss, influence odometry and gradually change as the tread, bearing and hub wear. That makes the wheel a mechanical interface, a motion-control input and a lifecycle component at the same time.
The practical answer to AGV wheel selection is therefore not “choose polyurethane” or “select a wheel whose catalog capacity exceeds total mass divided by the wheel count.” A defensible selection must identify the wheel’s function, its maximum and minimum reaction forces, the floor states it will encounter, the forces demanded during turning and stopping, the duration of those demands, the temperature produced by repeated deformation and the amount of dimensional or performance drift the application can tolerate.
This article develops a Wheel Duty Envelope for heavy-payload AMRs and AGVs. It begins where the related heavy-payload AMR traction engineering guide ends. That guide asks whether motor torque can become usable floor force. This guide asks whether the selected wheel can keep transmitting that force, carrying the load and preserving motion accuracy across the intended production life.
The distinction matters because a wheel can be strong enough not to collapse yet still be wrong for the application. It may run too hot, consume too much energy, scrub during turns, damage a coating, lose effective diameter, overload a bearing, debond from its core, develop flat spots or change the distance traveled per encoder count. A wheel rating can prove one boundary under one method. It cannot, by itself, prove a configured robot’s operating life.
Start with the Wheel Duty Envelope
The Wheel Duty Envelope is the set of conditions within which a named wheel assembly can perform its assigned role without unacceptable structural damage, thermal degradation, loss of traction, floor damage, motion error or maintenance burden. It is configuration-specific. Changing payload location, wheel diameter, top module, speed profile, floor coating or turning strategy can move the envelope even when gross mass remains unchanged.
A useful definition has six axes:
| Envelope axis | Questions that must be answered | Typical evidence |
|---|---|---|
| Wheel role | Is the assembly driving, supporting, steering, swiveling, guiding or producing omnidirectional force? | Architecture drawing, force-allocation model and mounting definition |
| Reaction envelope | What vertical, longitudinal, lateral, impact and moment loads reach this wheel in nominal and boundary cases? | Corner-scale data, calculation, simulation and instrumented route tests |
| Route envelope | Which coatings, joints, ramps, cross-slopes, plates, debris and contamination states are authorized? | Route survey, friction characterization and transition measurements |
| Motion envelope | What speed, acceleration, braking, pivoting, steering and docking cycles occur, and for how long? | Mission profile, controller logs and representative duty-cycle test |
| Environment | What temperature, humidity, chemicals, washdown, dust, ESD or cleanroom constraints apply? | Material compatibility records and application-specific verification |
| Allowed drift | How much diameter loss, runout, hardness change, bearing play, temperature rise or traction change is acceptable? | Acceptance limits, inspection method, trend rules and revalidation triggers |
This model prevents an important category error. The load capacity of heavy duty AGV wheels belongs only to the reaction axis. It says nothing by itself about heat in a continuous mission, turning scrub, chemical attack, electrical behavior, wheel-radius calibration or the consequence of wear at a precision station.
Four Budgets Must Close Before a Wheel Is Approved

The selection can be organized as four connected budgets. The wheel is acceptable only when all four close for the same configured machine and route.
1. Load budget
The load budget covers vertical reaction, side load, longitudinal force, shock, bearing load and mounting demand. Its starting point is not gross mass divided by the total number of wheels. It is the measured or calculated reaction history at each wheel position. Center-of-gravity offset, chassis flexibility, suspension preload, floor unevenness and dynamic transfer can make nominally identical wheels carry different loads.
A catalog capacity also has a test basis: wheel diameter, tread material, speed, duration, temperature, floor, bearing, duty classification and allowable deformation. Procurement should request that basis instead of treating the capacity number as a universal constant.
2. Contact budget
The contact budget describes what the wheel-floor pair can transmit and tolerate. It includes available adhesion, contact pressure, tread deformation, local floor pressure, obstacle crossing and lateral scrub. A wider or softer tread may spread load, but its larger contact patch can increase deformation and turning resistance. A crowned tread may turn more easily, but it can concentrate pressure. These are coupled trade-offs, not independent feature choices.
3. Energy budget
The energy budget follows power that is not converted into useful vehicle motion. Rolling resistance, tread hysteresis, bearing loss, caster swivel resistance, steering misalignment and tire scrub all consume energy. Some loss appears as battery demand; some becomes heat in the tread, bond line, bearing, gearbox or motor. The wheel must survive the peak and repeated thermal states created by the real mission.
4. Life budget
The life budget connects distance, revolutions, impacts, pivots, load cycles, starts, stops and environmental exposure to allowable degradation. It also includes the process consequence of degradation. Two wheels can lose the same millimeter of tread while creating very different risks: one application may tolerate the radius change, while another may lose docking accuracy, ground clearance or synchronization between driven sides.
The four-budget model is deliberately stricter than a simple material comparison. It asks whether the chosen wheel remains a valid part of the configured robot after production begins, not merely whether a new sample passes an initial roll test.
Separate Wheel Roles Before Comparing Materials

A heavy-payload chassis can contain several wheel types that look similar but experience different force systems. Combining them into one generic “wheel specification” hides the actual engineering.
Drive wheels transmit torque and close the traction loop
An AGV drive wheel carries a vertical reaction while transmitting longitudinal and sometimes lateral force. Its effective rolling radius connects motor speed to vehicle speed. Its compliance affects the contact patch and control response. Its hub, keyway, spline, clamping interface or bonded core must transmit alternating torque without loosening or fretting.
Drive-wheel selection must therefore connect motor torque, gearbox ratio, continuous power, traction demand, driven-wheel normal load, tread temperature and allowable slip. A high-capacity support wheel is not automatically suitable as a powered wheel, even if its diameter and material look similar.
Load wheels carry mass but still influence motion
Load wheels may not receive motor torque, but they influence rolling resistance, chassis attitude, floor pressure, vibration and the amount of weight remaining on the driven wheels. If a suspension setting or floor feature transfers too much load onto passive supports, the vehicle can become adhesion-limited even though total payload is unchanged.
Caster wheels add swivel and shimmy behavior
AGV caster wheel selection must include offset, trail, swivel-bearing friction, fork stiffness, wheel diameter, tread contour and the direction of approach to joints. A caster can carry its static load correctly yet create high breakaway force, shimmy at speed, snap into alignment during reversal or unload a drive wheel during a transition.
For differential-drive vehicles, pivot turns deserve special attention. The caster must swivel while the drive wheels scrub across the floor. A dual-wheel caster may increase capacity and reduce some contact pressure, but differential action between the two wheels and the swivel construction still determine turning resistance.
Omnidirectional rollers operate under directional constraints
Mecanum and other omnidirectional assemblies distribute contact through angled rollers. Roller material, bearing play, roller diameter variation and load sharing influence vibration, directional force, odometry and floor marking. A total wheel rating does not reveal the peak load on an individual roller or the force available in every travel direction.
The site’s heavy-payload chassis drive-type guide compares differential, steered, omnidirectional and Mecanum layouts at architecture level. The Wheel Duty Envelope adds the component-level evidence needed after the architecture has been chosen.
Wheel Load Is a Time History, Not Gross Mass Divided by Wheel Count
The first serious AMR wheel load calculation should establish individual reactions for the actual assembly. A six-wheel robot does not necessarily divide its mass by six. Manufacturing tolerances, frame twist, suspension settings, tire diameter, CG position and floor profile decide which contacts are truly supporting the vehicle.
Measure the static starting condition

Place the configured robot on a controlled, level surface and measure each wheel reaction with suitable scales or load cells. Record payload, fixture, top module, battery state, lift position, wheel part numbers, tire condition, suspension settings and floor condition. Repeatability matters: if reactions change materially when the vehicle approaches the scales from different directions, compliance, caster orientation or hysteresis may be influencing the result.
The sum of reactions should reconcile with gross weight within the measurement uncertainty. The individual values should then be compared with the structural and thermal basis of each wheel assembly, not only with a nominal static capacity.
Add the dynamic cases that move reaction forces
Acceleration and braking transfer load longitudinally. Turning and cross-slope transfer it laterally. A ramp changes both attitude and traction demand. A joint can create a short-duration impact and temporarily reduce contact elsewhere. A transfer station can support part of the payload outside the chassis. A raised lift can change CG height and moment. Each event changes which wheel is critical.
The companion heavy-payload AMR load-path guide explains how these reactions travel from payload to frame, wheel mounts and floor. The dynamic-stability guide explains why lateral acceleration, CG height and support geometry must be reviewed together. Wheel selection should consume those results rather than invent a separate, simplified load case.
Protect minimum drive-wheel load as well as maximum wheel load
Most component reviews focus on the maximum reaction because it drives stress and heat. A mobile robot also needs a minimum reaction on each driven wheel. Too little normal force can reduce usable adhesion, impair yaw control and increase slip. The valid design window may therefore have an upper limit for wheel durability and a lower limit for traction authority.
This is one reason a payload can make motion worse even when total mass increases. If its offset shifts weight away from a driven wheel and onto passive supports, the robot can carry more mass while having less usable force at the drive contact.
Polyurethane Is a Family, Not a Complete Specification
Many industrial robots use polyurethane AGV wheels because engineered polyurethane systems can combine load capacity, floor protection, wear resistance and controlled resilience. But “PU wheel” is not a sufficient material specification. Formulation, hardness scale, rebound, hysteresis, tensile and tear behavior, compression set, tread thickness, cure, core preparation and bond quality all influence performance.
Hamilton Caster’s official polyurethane wheel overview explicitly states that no single polyurethane is universally best and presents different compounds and hardness ranges for different duties. Covestro’s official Vulkollan material information highlights low energy loss, limited heat build-up, rebound resilience and resistance to mechanical and environmental demand as separate material attributes. The engineering lesson is broader than either product family: hardness alone cannot represent dynamic performance.
Harder is not automatically better
A harder tread generally deforms less under a given load and may reduce rolling loss on a smooth floor. It may also increase load capability within a manufacturer’s design. However, it can transmit more shock, produce higher local pressure, reduce conformity over debris and change adhesion. A softer tread can improve damping and contact conformity, but may increase hysteresis, temperature and dimensional change.
Do not compare a Shore A value with a Shore D value as if the numbers share one linear scale. Do not specify hardness without tolerance, test method and temperature. Do not assume that two compounds with the same durometer have the same rebound, tear strength, wear or heat generation.
Bonding can govern before the tread wears out

A bonded wheel is a composite assembly. Torque and deformation create shear at the tread-core interface. Heat, moisture, chemicals, impact and processing quality can weaken the bond. Inspection should therefore distinguish normal tread wear from edge lifting, blistering, circumferential cracking and progressive debonding. A thick tread with a weak or overheated bond is not a long-life wheel.
Material compatibility belongs to the route
Oil, cleaning chemicals, metalworking fluids, hot water, humidity, ozone, chips and abrasive dust can alter tread or bond performance. The correct industrial robot wheel material is the one whose documented compatibility and physical test evidence match the actual concentration, temperature, contact time and cleaning process. A generic statement such as “chemical resistant” is too broad for approval.
Route-specific exposure should be connected to the heavy-payload AMR floor requirements. Floor and wheel are one tribological pair: changing either member can change traction, rolling resistance, wear and marking.
Geometry Changes Motion, Heat and Damage
Diameter changes obstacle response and rotational duty

A larger diameter generally approaches joints, gaps and debris with a more favorable geometry. It also turns fewer revolutions for the same travel distance. Hamilton’s official selection guidance identifies diameter as a major factor in rollability, while its wheel test metrics connect footprint, tread compliance and rolling force.
For a driven wheel, diameter also changes the relationship between motor torque and floor force:
Fwheel = Twheel / reffective
A larger radius reduces theoretical force for the same wheel torque, even while improving obstacle crossing and reducing revolutions. It can require a different gear ratio, motor operating point or control calibration. It can also change deck height, ground clearance, sensor height and mechanical packaging.
Width and contour trade pressure against scrub
A wider tread can increase contact area and reduce average pressure, but width does not guarantee equal load distribution across the face. Misalignment, camber, frame deflection or a crowned floor may load one edge. Wide, flat tires can also demand more torque during pivot turns because more material is sheared across the floor.
A crowned tread can reduce scrub and self-align more easily, but its smaller initial footprint can increase local pressure. The correct contour depends on whether the wheel must maximize load, transmit drive force, swivel, pivot, protect a coating or cross irregularities.
Tread thickness and core design affect thermal behavior
Thicker resilient material may absorb irregularities and spread some stress, but it also creates more deforming material. Compound selection, rebound and heat conduction through the core become important. Aluminum, steel and cast iron cores differ in stiffness, mass, corrosion behavior, machining, thermal conduction and interface design. The correct choice depends on the assembly, not a universal hierarchy.
Bearings and mounting interfaces belong in the wheel specification
Bearing type, bore tolerance, axle fit, spacer stack, preload, lubrication, seal drag and contamination protection can change both resistance and life. A wheel may be rated for a high radial load while the actual bearing arrangement is vulnerable to thrust, misalignment or impact. Drive wheels additionally require a torque-transfer interface with controlled fit and retention.
Procurement should treat the complete rotating assembly as the unit of evidence: tread, core, bond, bearing, axle or hub connection, fasteners, guards and inspection access.
Rolling Resistance Is a System KPI
Rolling resistance is often entered once in a motor-sizing spreadsheet and then forgotten. In production it is a changing system output. It depends on wheel material, diameter, load, temperature, bearing condition, floor roughness, contamination and maneuver. For a screening calculation:
Frr ≈ Crr × N
Prr ≈ Frr × v
These equations are useful only when the coefficient represents the wheel-floor pair and operating state being reviewed. A value measured on clean, smooth concrete with new wheels may not represent a dusty route, a rough coating, hot tread or worn bearings.
Higher rolling resistance can increase mission energy, motor current and thermal load. It can reduce acceleration reserve and grade capability. If resistance differs from left to right, the controller must correct yaw, potentially increasing tire work and energy again. If it rises gradually, it may be an early indicator of AMR wheel wear, bearing degradation, contamination or misalignment.
This creates a valuable diagnostic opportunity. Compare commanded speed, actual speed, motor current, wheel temperature and route segment over time. A current increase that appears only on one surface suggests a contact-state change. A persistent increase on every route suggests vehicle condition. A rise only during pivots suggests scrub, caster or steering behavior rather than straight-line rolling loss.
The Thermal Problem Hidden Inside Continuous Duty
Resilient tread repeatedly deforms as it enters and leaves the contact patch. Because the material does not return all deformation energy elastically, part of the energy becomes heat. Higher load, speed, deformation, rolling resistance and continuous operating time can increase thermal demand. Frequent pivoting adds shear work. A joint-rich route adds repeated impacts. A hot ambient environment reduces cooling margin.
This is why a static capacity is not automatically a continuous-duty rating. It is also why a short demonstration can pass while production fails hours later. The wheel may reach a stable temperature at one mission intensity and continue heating at another.
Ask for time-to-temperature behavior
A useful test records tread or near-tread temperature, hub temperature, bearing temperature, motor current, speed, payload and ambient condition from cold start through thermal stabilization. The test should reproduce the route’s turning, stopping, joint crossing and dwell pattern. The result is not just a peak temperature; it is a curve showing whether the assembly approaches a stable state and how much performance changes as it warms.
Separate component temperature limits
The tread compound, bond line, lubricant, bearing, seal, encoder and nearby gearbox may have different limits. Surface temperature alone may not reveal the hottest internal location. The test method and sensor position should be preserved so future measurements remain comparable.
Thermal drift can become control drift
As a resilient wheel warms, its deformation and effective rolling radius may change. The result can appear as altered odometry, unequal left-right travel, changed current or a different docking correction pattern. A thermal review should therefore connect material condition to vehicle behavior rather than treating temperature as a maintenance-only statistic.
Worked Engineering Screen: Two Wheels with the Same Capacity Claim
Consider an illustrative 2,400 kg configured vehicle operating at up to 1.5 m/s. The application requires 6,000 km of annual travel and includes repeated joints and pivot turns. Two candidate drive wheels both appear to meet the supplier’s nominal load capacity:
| Screening input | Candidate A | Candidate B |
|---|---|---|
| Nominal diameter | 160 mm | 200 mm |
| Tread concept | Harder, thinner resilient tread | Application-specific high-rebound tread |
| Supplier capacity | Acceptable under stated catalog method | Acceptable under stated catalog method |
| Application questions | Higher revolutions and joint frequency; potentially lower deformation on smooth floor | Lower revolutions and improved joint geometry; different torque and packaging requirement |
Rotational duty
At 1.5 m/s, the ideal wheel speed is approximately:
- Candidate A, 160 mm: about 179 rpm;
- Candidate B, 200 mm: about 143 rpm.
Across 6,000 km, the 160 mm wheel completes about 11.94 million revolutions, while the 200 mm wheel completes about 9.55 million. Candidate A therefore experiences roughly 25% more revolutions for the same route distance. That does not prove it will have shorter life, because compound, bearing, load and temperature also matter. It does prove that equal kilometer targets do not create equal rotational duty.
Rolling-loss sensitivity
The configured weight is approximately 23.5 kN. If the effective route-level rolling-resistance coefficient rises illustratively from 0.020 to 0.030, rolling demand increases from about 471 N to 706 N. At 1.5 m/s, that is approximately 353 W of additional mechanical power. Across 6,000 km, the difference represents about 392 kWh of additional mechanical work before drivetrain and charging losses.
The calculation does not select Candidate A or B. The coefficients must be measured or supported for the actual wheel-floor pair. The calculation shows why a small change in rolling behavior can become a fleet-level energy and thermal issue.
Reaction distribution
Suppose two driven wheels should carry 62% of static weight. An ideal centered calculation gives about 7.3 kN per drive wheel. Corner-scale testing instead finds 6.7 kN on one side and 7.9 kN on the other because the top module and payload are offset. The higher-loaded wheel now deserves the thermal and structural review; the lower-loaded wheel may govern available adhesion during a maneuver. One average value hides both problems.
Screening limitation: The figures above are educational, not a product recommendation or approval value. Final selection requires supplier data, actual configuration measurements, route characterization and physical validation.
Wheel Wear Changes More Than Maintenance Cost

A worn wheel can remain visibly intact while changing system behavior. This is why AMR wheel maintenance should be connected to performance limits rather than limited to a visual check for catastrophic damage.
Effective diameter changes odometry and synchronization
Wheel encoders convert rotation into estimated travel using an effective radius. Tread loss, compression, temperature and load change that radius. If left and right drive wheels change differently, a differential-drive controller can accumulate yaw error or correction effort. Localization may compensate at system level, but that does not mean the mechanical drift is harmless. It can increase tire work, current and docking variation.
Runout and flat spots create periodic disturbance
Out-of-round tread, flat spots, eccentric mounting or local chunking can create a repeating vertical and speed disturbance. The frequency follows wheel speed, which makes it detectable in accelerometer, current or vibration data. The consequence may include payload vibration, sensor disturbance, fastener loosening, noise or degraded transfer alignment.
Hardness and surface condition change contact behavior
A tread can polish, glaze, cut, crack, absorb contamination or thermally age. These changes may affect adhesion and rolling resistance before the diameter reaches a replacement threshold. Inspection should preserve surface photographs and location because one-sided wear can reveal misalignment or repeated route geometry.
Bearing and swivel wear change force demand
Increased bearing play can alter wheel attitude and runout. Increased seal or bearing drag raises current and heat. Caster swivel wear can create unstable alignment or shimmy. A wheel-only tread measurement will miss these failure modes.
Stopping performance is another downstream consumer. The site’s heavy-payload AMR stopping-distance guide explains why wheel condition, floor state and load distribution affect the verified stop envelope. A wheel replacement or wear limit should be reviewed against that evidence, not treated as an isolated maintenance decision.
Build a Wear Signature, Not a Calendar-Only Replacement Rule
A fixed service interval is useful for planning, but it cannot represent every route and duty cycle. A mature program combines elapsed time with distance, operating events, measured condition and performance trend.
| Condition indicator | Possible interpretation | Decision it should support |
|---|---|---|
| Diameter and tread-depth loss | General wear, unequal loading or route abrasion | Calibration review, pairing rule and replacement limit |
| Radial and lateral runout | Flat spot, eccentric mounting, core or bearing issue | Vibration investigation and removal criterion |
| Tread or hub temperature trend | Hysteresis, overload, bearing drag, misalignment or duty increase | Restricted operation, lubrication, alignment or thermal revalidation |
| Current per route segment | Rolling resistance, scrub, bearing degradation or floor change | Targeted inspection and route comparison |
| Slip or localization correction trend | Contact change, unequal radius, contamination or traction loss | Wheel-floor investigation and motion-limit review |
| Cracks, cuts, chunking or bond-edge change | Impact, fatigue, chemical attack, overheating or bonding defect | Immediate engineering disposition and supplier analysis |
| Bearing play, noise or swivel resistance | Wear, contamination, lubrication loss or mounting damage | Bearing or complete assembly replacement |
The project must define the limits. There is no responsible universal rule such as “replace every wheel after 5,000 km” or “replace at 10% diameter loss” for all robots. The allowed drift depends on traction, clearance, docking, stability, encoder calibration, field geometry and supplier instructions.
An AGV wheel replacement rule should state the measurement method, limit, inspection frequency, pairing requirement, approved part and post-replacement checks. If drive wheels are replaced as a pair, the rule should explain why. If they can be replaced individually, the permitted diameter mismatch and calibration procedure should be defined.
Validate New, Boundary and Worn Conditions
Wheel validation should not end with a new set on a clean floor. The objective is to show that the configured vehicle remains inside its required envelope from release condition to the approved maintenance boundary.
Gate 1: component evidence

Record material system, hardness and tolerance, physical properties relevant to the duty, tread geometry, core material, bond process, bearing and seal, rated load basis, speed and duty restrictions, temperature limits, chemical compatibility and dimensional tolerances. Supplier declarations should be tied to a revision-controlled part number.
Gate 2: configured static evidence
Measure wheel reactions, ride height, effective diameter, runout, alignment, ground clearance, caster orientation behavior and electrical resistance where relevant. Verify that the configured assembly—not an ideal CAD model—matches the assumptions used for selection.
Gate 3: route-event evidence
Test representative straight travel, acceleration, braking, turning, pivoting, reverse transitions, ramps, cross-slopes, joints, docking and load transfer. Include the authorized payload families and floor states. Measure current, speed, wheel or hub temperature, slip indicators, localization corrections and any application-critical vibration.
Gate 4: thermal-duty evidence
Run the representative mission long enough to understand temperature stabilization and performance drift. A short maximum-load lap does not reproduce a multi-shift duty cycle. Where accelerated testing is used, justify how load, speed, temperature and failure mechanisms correspond to production rather than simply increasing severity.
Gate 5: maintenance-boundary evidence
Evaluate the vehicle at or near the proposed wear limit, using naturally aged components, controlled wear specimens or a justified simulation supported by measurement. Confirm traction, braking, docking, clearance, motion accuracy and diagnostics. The maintenance limit is credible only if the vehicle still satisfies its authorized function at that boundary.
Gate 6: replacement and recovery evidence
Demonstrate safe isolation, lifting or jacking, wheel removal, torque procedure, calibration, paired-component rules and post-service verification. A wheel may be technically suitable but operationally expensive if access requires major disassembly or if replacement introduces uncontrolled alignment.
What a Buyer Should Request in the Wheel Evidence Record
A buyer should request a configuration-controlled record rather than a line item saying “PU wheel, 95A.” The record should include:
- wheel function and location on the vehicle;
- manufacturer, part number, revision and approved alternatives;
- tread material system, hardness scale, tolerance and test condition;
- diameter, width, contour, tread thickness, core and mass;
- bearing, seal, bore, shaft, keyway, spline or clamping interface;
- static and dynamic reaction envelope at each wheel position;
- torque, side load, speed, impact and continuous-duty basis;
- authorized floor, ramp, joint, contamination and temperature conditions;
- rolling-resistance, adhesion and thermal evidence for the wheel-floor pair;
- dimensional, visual, temperature, vibration and performance inspection methods;
- warning, restriction and replacement limits;
- approved service procedure and post-service verification;
- change-control and revalidation triggers.
This record can be integrated into the site’s heavy-payload AMR buying and acceptance guide. The buying guide establishes the commercial and system requirements; the wheel record provides the detailed evidence for one critical lifecycle interface.
ESD, Cleanroom and Chemical Claims Need System Evidence
Electrically conductive, dissipative, antistatic and non-marking are not interchangeable claims. A wheel compound may have a stated electrical property, but the complete path through tread, core, bearings, axle and chassis must support the intended function. Floor resistance, contamination, humidity and maintenance can also change system behavior.
IEC 61340-5-1:2024 provides requirements for an ESD control program for protection of electronic devices. It does not mean that buying a wheel labeled “ESD” automatically validates the mobile robot or the facility process. The project must define the applicable ESD control requirement, measurement method, system path and compliance-verification routine.
Cleanroom and food or pharmaceutical applications add particle, outgassing, cleaning and material-compatibility questions. A non-marking wheel can still shed particles. A chemically resistant tread can still have an unsuitable lubricant, seal or exposed core. Qualification should address the complete assembly and the actual cleaning regime.
Management of Change: A Wheel Swap Can Move the Operating Envelope

A replacement that fits the axle is not necessarily equivalent. Changes in compound, hardness, diameter tolerance, tread contour, core, bearing drag, electrical behavior or effective radius can affect traction, braking, energy, stability, localization and safety-field performance.
ISO 3691-4:2023 covers safety requirements and verification for driverless industrial trucks and recognizes that operating-zone condition materially affects safe operation. The official edition status is listed by ISO. In the United States, ANSI/A3 R15.08-3-2026 emphasizes continued safe use, risk assessment and management of change over the application lifecycle. Neither source supplies a universal wheel safety factor or replacement interval; they reinforce the need to control the configured application and its changes.
The user should define which wheel changes are like-for-like maintenance, which require engineering review and which require targeted or full revalidation. Triggers should include:
- new wheel manufacturer, compound, hardness or core;
- diameter, width, contour or tread-thickness change;
- bearing, seal, axle or mounting change;
- new payload family, CG position or top module;
- higher speed, acceleration, braking or pivot frequency;
- new floor coating, route, ramp, joint or contamination state;
- software changes affecting torque allocation, slip control or odometry;
- wear, temperature, current or stopping trends approaching the approved boundary.
A Release Rule for the Engineering Team
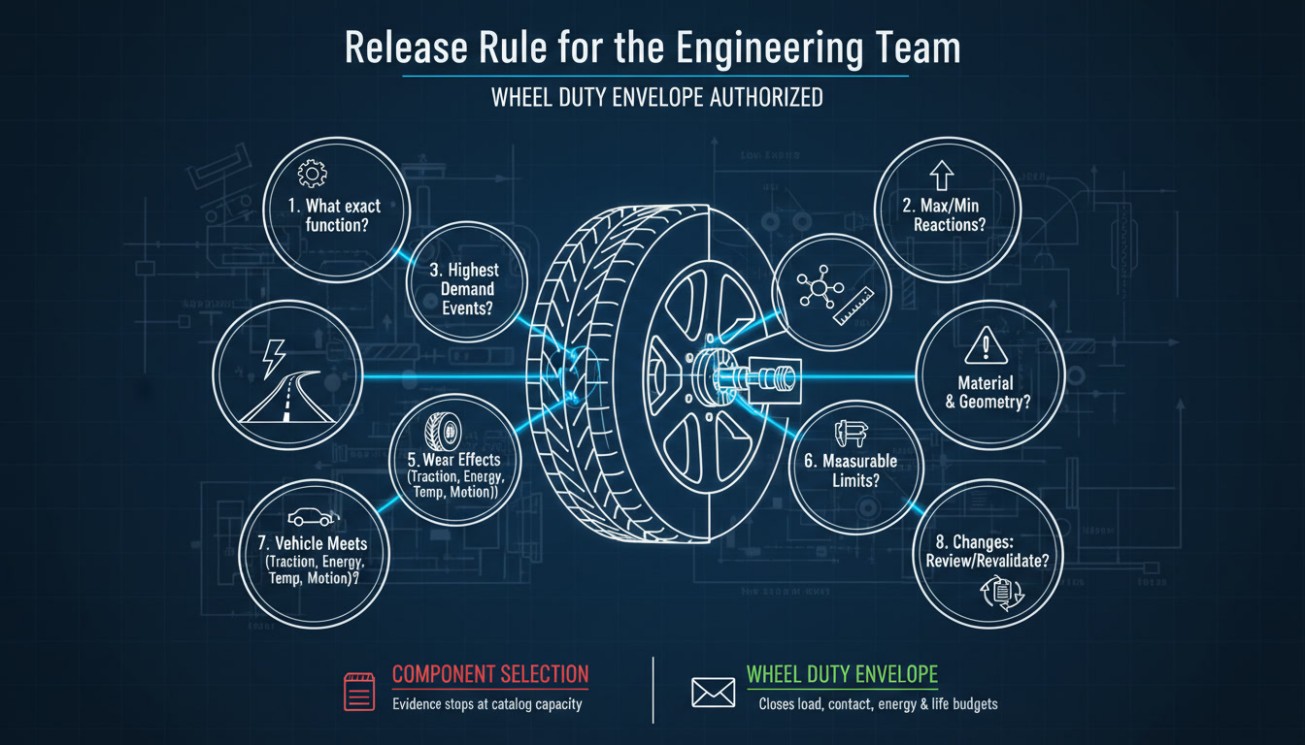
A wheel assembly is ready for production only when the team can answer all of the following with configuration-controlled evidence:
- What exact function does each wheel perform?
- What are the maximum and minimum reactions at every wheel position?
- Which route events create the highest structural, contact and thermal demand?
- Which material and geometry properties are necessary for those events?
- What happens to traction, energy, temperature and motion accuracy as the wheel wears?
- What measurable limit defines inspection, restriction and replacement?
- Does the configured vehicle still meet its functional and safety requirements at that limit?
- Which changes require review or revalidation?
If the evidence stops at catalog capacity, the project has selected a component. If it closes the load, contact, energy and life budgets, the project has authorized a Wheel Duty Envelope.
Focused FAQ
What is the best wheel material for a heavy-payload AMR?
There is no universal best material. The choice depends on wheel role, individual reaction load, floor, traction, speed, turning, temperature, chemicals, ESD needs, noise and allowable wear. Polyurethane is common, but formulation, hardness, rebound, geometry and bonding must match the application. Rubber, nylon, steel and specialized elastomers can be appropriate in different envelopes.
Can wheel capacity be calculated by dividing robot mass by the number of wheels?
No. That can be an initial arithmetic check only when geometry and support are ideal. Real wheel reactions change with CG offset, manufacturing tolerance, suspension, frame twist, caster orientation, ramps, turning, braking and floor irregularity. Measure the configured static reactions and calculate or test dynamic cases.
Does a harder polyurethane wheel always carry more load?
Not as a universal rule. A manufacturer may offer higher capacity with a harder formulation, but hardness alone does not define dynamic capacity, heat, rebound, tear behavior, adhesion, bonding or floor interaction. Compare complete wheel designs under a stated test and duty basis.
Why do heavy-payload AMR wheels overheat?
Heat can result from repeated tread deformation, high rolling resistance, overload, speed, continuous duty, pivot scrub, bearing drag, misalignment, floor roughness or high ambient temperature. Instrumented mission testing should separate where energy is being lost instead of assuming the tread compound is the only cause.
How does wheel diameter affect AMR performance?
Larger wheels generally encounter joints and debris with more favorable geometry and complete fewer revolutions per kilometer. For drive wheels, a larger radius also reduces theoretical floor force for the same wheel torque and changes motor speed, gearing, deck height and calibration. Diameter must therefore be selected with the whole drive and chassis.
When should an AGV or AMR wheel be replaced?
Use application-specific limits for diameter, tread depth, runout, damage, bond condition, bearing play, temperature and performance drift. Add event-driven replacement after impact, chunking, debonding or abnormal heat. A universal kilometer or percentage rule is not defensible without connection to the configured vehicle’s functional limits.
Should both drive wheels be replaced together?
Often a paired replacement helps control diameter and traction symmetry, but it is not a universal requirement. The manufacturer or integrator should define the permitted mismatch, calibration method and post-service verification. If individual replacement is allowed, evidence should show that yaw control, odometry, braking and docking remain acceptable.
Can operational current data predict wheel wear?
Current trends can reveal increased rolling resistance, scrub, bearing drag or route change, especially when compared by vehicle, payload and route segment. Current alone cannot identify the cause or replace physical inspection. It is most useful as one signal within a condition-monitoring model that also uses temperature, vibration, slip, diameter and visual evidence.
What should be checked after fitting a replacement wheel?
Verify part identity, dimensions, mounting torque, bearing condition, free rotation, clearance, reaction distribution, effective radius or calibration, straight travel, turning, braking, docking and any ESD function. The depth of testing should reflect whether the change is a controlled like-for-like replacement or a new configuration.
Conclusion: Approve a Wheel Duty Envelope, Not a Material Name
A wheel is where payload, chassis, drive, floor and production duty become one physical event. Selecting it by material name and static capacity ignores the variables that most often separate a successful pilot from stable multi-shift operation.
The stronger method closes four budgets. The load budget protects the structure and bearings. The contact budget protects traction and floor interaction. The energy budget controls rolling loss and heat. The life budget defines how far performance may drift before inspection, restriction or replacement. All four must refer to the same wheel role, vehicle configuration, route and mission.
When this Wheel Duty Envelope is measured and maintained, wheel decisions become auditable. Procurement can compare suppliers on evidence instead of adjectives. Controls engineers can connect radius and traction changes to motion behavior. Maintenance can act on measurable limits. Safety and operations can understand which substitutions or route changes require revalidation.
The result is not simply a longer-lasting wheel. It is a heavy-payload mobile robot whose traction, energy use, docking, braking and lifecycle performance remain explainable after commissioning day.
#HeavyPayloadAMR #AGVWheelSelection #HeavyDutyAGVWheels #PolyurethaneAGVWheels #AGVDriveWheel #AMRWheelLoad #RollingResistance #AMRWheelWear #AGVWheelReplacement #AMRMaintenance

