Heavy-Payload AMR Stopping Distance How Load, Speed, Floor and Control Define the Stop
A Heavy Robot Does Not Have One Stopping Distance
The direct engineering answer is simple: a heavy-payload autonomous vehicle does not have one universal stopping-distance number. It has a family of stopping outcomes produced by a specific vehicle configuration, payload, speed, direction, floor, slope, control state and component condition. A catalog value can describe one test condition. It cannot, by itself, authorize every production route.
This is why heavy-payload AMR stopping distance should be treated as an operating envelope, not as a line in a brochure. The envelope must answer a more useful question: under the worst credible combination of authorized load, motion and environment, how far does the complete system travel after the relevant safety event begins, and does the vehicle, payload and surrounding process reach the required safe state before contact or instability occurs?
The distinction matters because “the robot stopped” is not necessarily the same as “the hazard ended.” A tall rack can continue to sway after wheel speed reaches zero. An unsecured carrier can slide on the top module. An overhanging fixture can enter a pedestrian space before the chassis nose reaches it. A vehicle can stop longitudinally while rotating slightly because left and right wheel forces were unequal. A load can remain stable during a routine deceleration but shift during an abrupt fault response.
Stopping therefore belongs to system engineering. It connects sensing, safety logic, communications, motor control, brakes, tires, wheel-load distribution, floor friction, center of gravity, load restraint, route geometry and maintenance. The existing heavy-payload AMR safety framework explains why safety cannot be reduced to sensors. This guide goes one level deeper and turns one critical safety outcome—the stop—into a calculation, measurement and validation problem.
The Stop Begins Before the Brakes Produce Force
Teams often measure from the moment they hear a brake or see the vehicle decelerate. That misses the first part of the event. A mobile robot keeps moving while the sensor confirms an intrusion, the safety logic evaluates it, a stop request propagates, the drive responds and braking force builds. For a fast, heavy vehicle, even a short delay can consume meaningful route length.
The nine-link stopping event chain

- Exposure begins. A person, truck, pallet or fixed boundary becomes relevant to the vehicle’s current motion.
- The sensing system acquires the condition. Scanner cycle time, filtering, field selection and object geometry influence when a valid detection exists.
- The safety function recognizes the event. The system determines that the active field or monitored condition requires a response.
- The signal propagates. Safety I/O, controller cycles, networks and drive interfaces add response time.
- The drive changes state. Propulsion torque is removed or commanded deceleration begins.
- Braking force builds. Electric, regenerative, dynamic or mechanical braking produces force through the wheels.
- The tire-floor interface transmits force. Available friction, wheel contact and local contamination limit what the commanded brake can achieve.
- The chassis reaches zero ground speed. Translation may end, but yaw, wheel slip or suspension motion may still need to settle.
- The combined system reaches a safe state. The payload remains retained, the vehicle does not roll, restart is inhibited as required, and no part of the configured machine has entered an unacceptable space.
This chain explains why an AMR stopping distance result belongs to the configured application, not only to the brake component. A faster scanner does not compensate for poor traction. A powerful brake cannot recover distance already consumed by excessive logic delay. A short chassis stop does not protect a load that continues moving relative to the chassis.
Four distances that should not be confused
- Detection distance
- The spatial relationship between the relevant object and the sensing boundary when detection becomes valid.
- Response distance
- The distance traveled from the defined detection or stop trigger until effective deceleration begins.
- Braking distance
- The travel from effective deceleration onset until the defined zero-motion condition is reached.
- Total stopping distance
- The response distance plus braking travel, measured between defined and repeatable start and end events.
The protective field is not another name for total stopping distance. It is a safeguarding geometry that must be sized from the complete risk-control design. It may need to account for the measured stop, sensor and system tolerances, vehicle contour, load overhang, travel direction, localization or field-switching uncertainty and an application-specific allowance. SICK’s engineering explanation of protective-field sizing similarly separates vehicle braking travel from scanner and safety-control response contributions. The practical lesson is that an AMR safety field calculation must be tied to measured system behavior and the actual configured contour, not copied from a generic robot diagram.
A Screening Model: Useful for Questions, Insufficient for Approval
A simple model helps buyers expose weak assumptions before detailed design. It should be used as an engineering screen, not as a substitute for the manufacturer’s safety functions, the application risk assessment or instrumented validation.
s_total = s_response + s_brake + s_application
For an initial straight-line screen:
s_response ≈ v0 × t_response
s_brake ≈ v0² / (2 × a_effective)
Here, v0 is speed at the defined trigger, t_response is the elapsed time before effective deceleration, and a_effective is the representative deceleration actually achieved in the tested condition. The application term is not a universal number. It represents justified allowances and geometry required by the risk-control design; it must not be invented as an arbitrary percentage.
Speed attacks the stop in two different ways
Response distance grows approximately in direct proportion to speed. Ideal braking distance grows with the square of speed when effective deceleration is unchanged. That creates an important operational consequence: doubling authorized speed roughly doubles the distance consumed during a fixed delay and quadruples the ideal braking term.
This is why a small speed increase can force a disproportionate increase in protective-field length. It can also make a previously acceptable blind crossing or narrow transfer zone impossible without route controls. When space is fixed, speed is often the most powerful design variable. It should be governed by zone and configuration, not negotiated late as a throughput patch.
A worked screening example

Consider a vehicle traveling at 1.5 m/s. Assume the defined sensing-to-deceleration response is 0.18 seconds and the measured effective deceleration for the relevant condition is 0.75 m/s².
s_response ≈ 1.5 × 0.18 = 0.27 m
s_brake ≈ 1.5² / (2 × 0.75) = 1.50 m
The screened total before any application-specific allowance is therefore about 1.77 m. At 1.0 m/s with the same response and deceleration assumptions, the corresponding screen is approximately 0.85 m. The 50% speed increase has more than doubled the screened distance.
These figures are illustrative, not product claims and not acceptance limits. Real deceleration is not perfectly constant, response stages may not be independent, and a loaded vehicle can exhibit jerk, slip, yaw and controller intervention. The value of the example is the causal structure: it shows which quantities must be specified, measured and controlled.
Why Mass Cancels in the Ideal Formula but Load Still Changes the Real Stop

One of the most useful corrections to common heavy-load language is this: mass does not appear explicitly in the ideal constant-deceleration distance formula above. If two vehicles enter a stop at the same speed and both sustain exactly the same effective deceleration, their ideal braking distance is the same even if one is heavier.
That does not mean payload is irrelevant. It means “more mass automatically creates more distance” is an incomplete model. Load changes whether the assumed deceleration can be produced, sustained and tolerated.
Brake energy increases with mass
The kinetic energy that must be removed is:
E_k = 1/2 × m × v²
At the same speed, doubling gross mass doubles the energy that must be dissipated or recovered. The first stop may look acceptable while repeated stops increase motor, drive, resistor, brake or tire temperature. If the system limits torque to protect components, effective deceleration can fall. If friction characteristics change with temperature, the tail of the stopping distribution can move even when the nominal setting is unchanged.
Load distribution changes usable tire force
Gross mass does not divide evenly across wheels in every condition. Payload offset, top-module geometry, wheelbase, caster arrangement, suspension compliance, acceleration, grade and cross-slope redistribute normal loads. A driven or braked wheel that becomes lightly loaded may saturate earlier or slip. A heavily loaded wheel may deform more, heat more and alter rolling behavior.
This is why loaded AMR braking must be evaluated with individual wheel contact and control architecture in mind. A theoretical total floor-friction capacity is not automatically available to the braking system if torque is applied through only part of the wheel set or if load transfer reduces normal force on a critical wheel.
Center of gravity limits acceptable deceleration
A high or offset combined center of gravity increases pitch or roll moment during deceleration. The brake may be physically capable of a short wheel stop while the payload envelope requires a gentler profile to avoid load shift, fixture overload or loss of stability. The safe operating limit may therefore be set by the payload and support geometry before it is set by motor torque.
This is the connection between stopping and payload usability. A low, centered 1,000 kg block and a tall, offset 1,000 kg rack can demand different motion limits even on the same chassis. The site’s heavy-payload chassis selection guide establishes that weight is only one part of the load profile. Stopping validation turns that principle into measurable evidence.
Load restraint may be the limiting subsystem

If a pallet can slide on a lift plate, a tote can move inside a rack, or a fixture latch has insufficient capacity, aggressive deceleration can create a secondary hazard. The vehicle can meet its wheel-speed target and still fail the application. Load retention, anti-slip interfaces, stops, latches and fasteners must be evaluated for the defined deceleration and fault cases.
The Stop Envelope Has Five Axes
A robust project should replace a single stopping value with a controlled stop envelope. The envelope is a record of conditions within which stopping performance has been demonstrated and authorized. Five axes prevent important variables from disappearing inside one average.
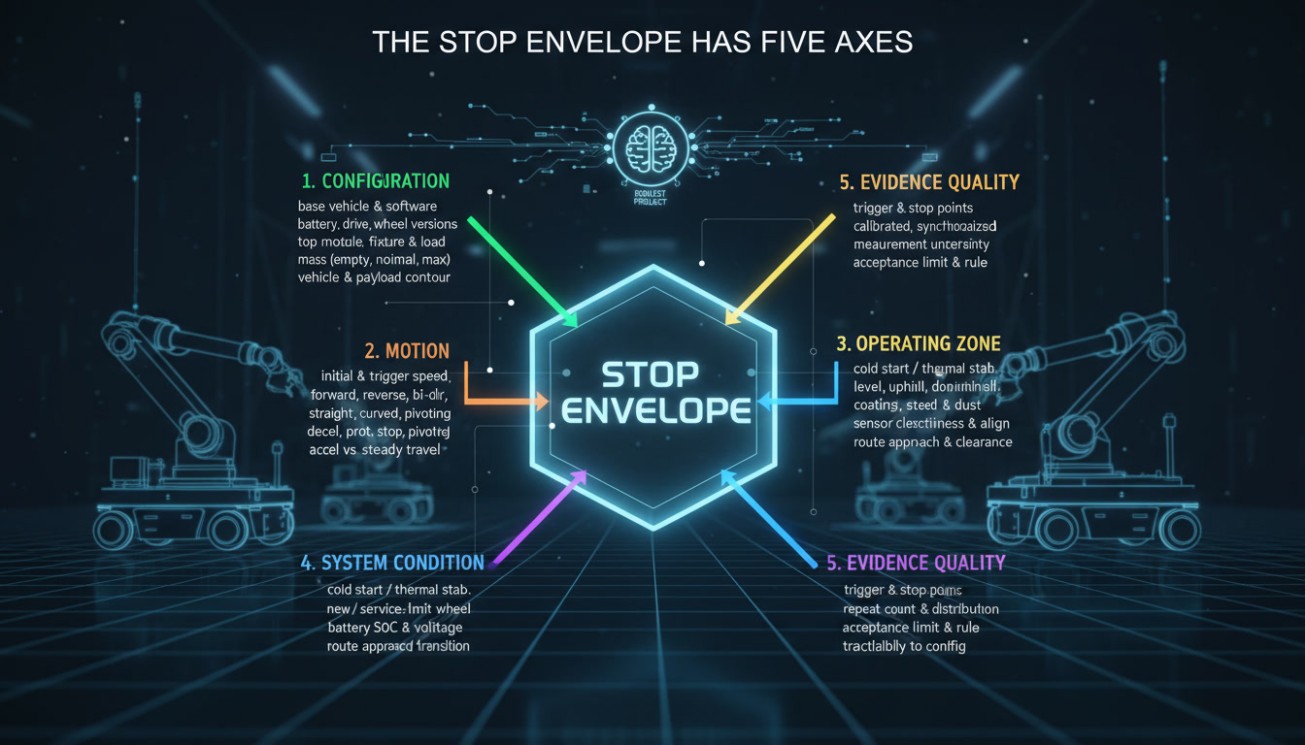
Axis 1: Configuration
- base vehicle and software release;
- battery, drive, brake, wheel and suspension versions;
- top module, carrier, fixture and load-restraint design;
- empty, nominal and maximum gross mass;
- combined center-of-gravity height and longitudinal/lateral offset;
- vehicle and payload contour, including overhang.
A stop result without configuration identity is weak evidence. If a top module is replaced, the load moves outward, or wheel material changes, the record may no longer represent the production machine.
Axis 2: Motion
- initial speed and actual speed at trigger;
- forward, reverse and bidirectional travel;
- straight, curved and pivoting motion;
- normal deceleration, protective stop and emergency response;
- entry into the event while accelerating versus steady travel;
- route-zone transition and safety-field switching state.
A straight stop is not proof of a turning stop. During a curve, tire capacity is already being used to generate lateral force. The brake request adds longitudinal demand. Wheel-load transfer, steering angle and floor variation can produce yaw or widen the swept path. The relevant boundary may be lateral contour excursion, not only distance along the route centerline.
Axis 3: Operating zone
- dry, clean reference surface and the lowest-friction authorized condition;
- level floor, uphill, downhill and cross-slope;
- coatings, steel plates, joints and local repairs;
- temperature, moisture, dust and process contamination;
- route approach geometry and available clearance.
The operating zone is not background scenery. The official scope of ISO 3691-4:2023 explicitly recognizes that operating-zone condition significantly affects safe operation of driverless industrial trucks, including examples such as AGVs and AMRs. As of August 2026, the 2023 edition remains the published current edition while a third-edition DIS is in development. A draft should not be presented as a published requirement.
Axis 4: System condition
- cold start and thermally stabilized duty;
- new and service-limit wheel condition;
- brake adjustment and wear state;
- battery state of charge and voltage behavior;
- sensor cleanliness and alignment;
- normal network and permitted degraded modes.
A commissioning test captures Day 1. Production authorization must survive Day 300. Wear that extends stopping time can erode a field margin without creating an obvious daily alarm. The correct control is a maintenance and revalidation rule tied to measured performance, not confidence that the original test will remain true forever.
Axis 5: Evidence quality
- defined trigger and stop measurement points;
- calibrated instruments and synchronized timestamps;
- repeat count and raw result distribution;
- measurement uncertainty and environmental record;
- predefined acceptance limit and disposition rule;
- traceability to the authorized configuration.
One successful stop is an anecdote. A distribution begins to describe a process. For AGV braking performance, the engineering interest lies in the long-distance tail, its causes and its movement over time—not only in the average result.
Downhill and Turning Stops Expose Hidden Assumptions
Grade subtracts from available deceleration

For a simplified downhill screen, the component of gravity along the route reduces the net deceleration available to stop the vehicle:
a_effective ≈ a_brake - g × sin(θ)
This expression is useful for sensitivity analysis, but real results also depend on traction, drive topology, brake control, grade measurement, payload position and whether the system is designed and authorized for that slope. A slope percentage from a product sheet is not automatically a validated stopping condition. Climbing capability, holding capability and stopping capability answer different questions.
Downhill testing should also verify what happens after zero speed. Can the vehicle hold without creep? What happens if power changes state? Is a controlled recovery defined? Does releasing a brake during maintenance create a roll-away hazard? The stop is not complete if the machine cannot remain in the intended safe state.
Cross-slope changes left-right margin
Cross-slope shifts normal load laterally. Combined with an offset payload, it can create unequal traction, yaw or a reduced stability margin during braking. The same nominal floor-friction value does not guarantee symmetric wheel forces. Test direction matters: traversing the same cross-slope in the opposite direction can move the payload offset from uphill to downhill.
Turning uses the tire-force budget twice
A vehicle in a curve requires lateral force before braking begins. Adding a strong longitudinal command may exceed what one or more contacts can transmit. The result can be sliding, understeer, oversteer, steering-control intervention or load motion. A relevant AMR braking distance program therefore includes curved-path and combined braking cases when production missions can request or experience them.
Drive architecture affects these cases. Differential, steered and omnidirectional systems distribute forces and scrub differently, especially at high gross mass. The related heavy-payload drive architecture guide can be used to identify which wheel contacts and motion modes deserve dedicated tests.
Normal Stop, Protective Stop and Emergency Stop Are Different Questions
Using the word “stop” without naming the function creates ambiguous specifications. The project should define the initiating condition, commanded behavior, monitored response, final state and restart rule for each relevant stop type.
Routine or mission stop
A routine stop supports docking, traffic control, queueing and destination arrival. It is normally optimized for repeatability, payload protection, passenger-like smoothness and component life. Its comfortable profile should not be mistaken for the response available after a safety event.
Protective stop
A protective stop is initiated by a safeguarding condition and must reach the defined safe state through the validated safety architecture. Its behavior may include a controlled deceleration that is monitored by safety functions. The exact design is product- and application-specific.
Emergency stop
An emergency stop is a complementary protective measure for an emergency situation; it is not the primary strategy for routine obstacle detection. It should not be described casually as “the shortest possible stop.” For a heavy vehicle, instantly commanding the maximum mechanical response could introduce slip, yaw, load shift or instability. The safe function and stop category must come from the risk assessment and compliant design, not from an assumption that harsher always means safer.
An AMR emergency stop distance should therefore be recorded separately from routine and protective-stop results. The test must also verify payload behavior, holding state, fault indication and controlled restart or recovery. Comparing only chassis travel can hide the very hazard that the stop created.
In North America, A3’s official standards listing assigns vehicle design to R15.08 Part 1, system and application integration to Part 2, and day-to-day safe use to ANSI/A3 R15.08-3-2026. Part 3 was published on April 23, 2026 and emphasizes risk assessment, management of change and acceptable risk over operation. These standards provide responsibility and lifecycle context; they should not be misquoted as supplying one universal braking-distance value for every vehicle.
Protective Fields Must Follow the Verified Stop, Not Hide It
A common project failure is to tune scanner fields until the robot appears productive, then assume the field proves the stop. The causality runs the other way. First define and verify the maximum authorized stopping behavior under the relevant condition. Then establish field geometry and speed permissions so the safety objective remains satisfied.
A field design needs more than a brochure distance
The design should consider:
- vehicle travel during scanner and safety-control response;
- measured braking travel and its variation;
- active direction and field-set switching;
- vehicle, fork, fixture and payload contour;
- measurement, localization and configuration tolerances relevant to the design;
- floor, slope, turn and system-condition boundaries;
- the person or object interaction identified by the risk assessment.
The site’s AGV and AMR safety laser scanner guide explains warning fields, protective fields and field switching. This article adds the missing engineering discipline: every field set should trace back to a speed, configuration and verified stopping envelope.
Field switching creates a timing boundary
If a vehicle accelerates before the longer high-speed field is active, or if a shorter field remains active too long after a zone transition, the spatial protection can be inconsistent with actual motion. Validation should examine the transition, not only stable operation inside each zone. Record commanded speed, measured speed, selected field set and relevant timestamps on one trace.
Overhang changes what “before contact” means
A forward-projecting fork or fixture can be the first point of contact. A side overhang can sweep outward in a turn. A rear load can matter in reverse. The protected contour must represent the configured machine and permitted payload family, including credible placement variation. Scanner coverage that protects the base while ignoring the load is not a complete application design.
Build the Test Around the Worst Credible Stop
A strong AGV stopping test does not begin by asking how many repetitions are convenient. It begins by defining the claims that production will rely on. Each claim should have a configuration, condition, measurable limit and evidence owner.
Step 1: Freeze the test article
Record the vehicle serial number, bill-of-material revision, safety and motion software versions, brake and wheel specification, tire condition, top module, fixture, fasteners, battery, gross mass, load distribution, combined center of gravity and restraint method. Photograph the configuration and preserve a controlled drawing. If the production unit differs, the test report must identify whether the difference is covered or requires additional work.
Step 2: Define the stop matrix
| Dimension | Minimum useful cases | Reason |
|---|---|---|
| Payload | Empty, nominal, maximum mass, maximum authorized CG/offset | Separates gross-mass, wheel-load and stability effects |
| Speed | Each authorized speed zone, including transition entry | Captures linear response-distance and quadratic ideal braking sensitivity |
| Route | Level straight, reverse, curve, downhill, cross-slope where applicable | Exposes grade, combined-force and contour effects |
| Surface | Reference surface and lowest-friction authorized production condition | Tests tire-floor transmission rather than brake command alone |
| Stop function | Routine, protective and emergency responses as applicable | Prevents one function’s result from authorizing another |
| Condition | Cold, duty-cycle hot, maintenance-limit component states | Reveals thermal and wear-related drift |
Not every combination requires destructive full-energy testing. Analytical screening and staged, instrumented tests can eliminate irrelevant cases and control risk. But excluded combinations should be excluded by documented reasoning, not by omission.
Step 3: Measure the event, not only the final mark
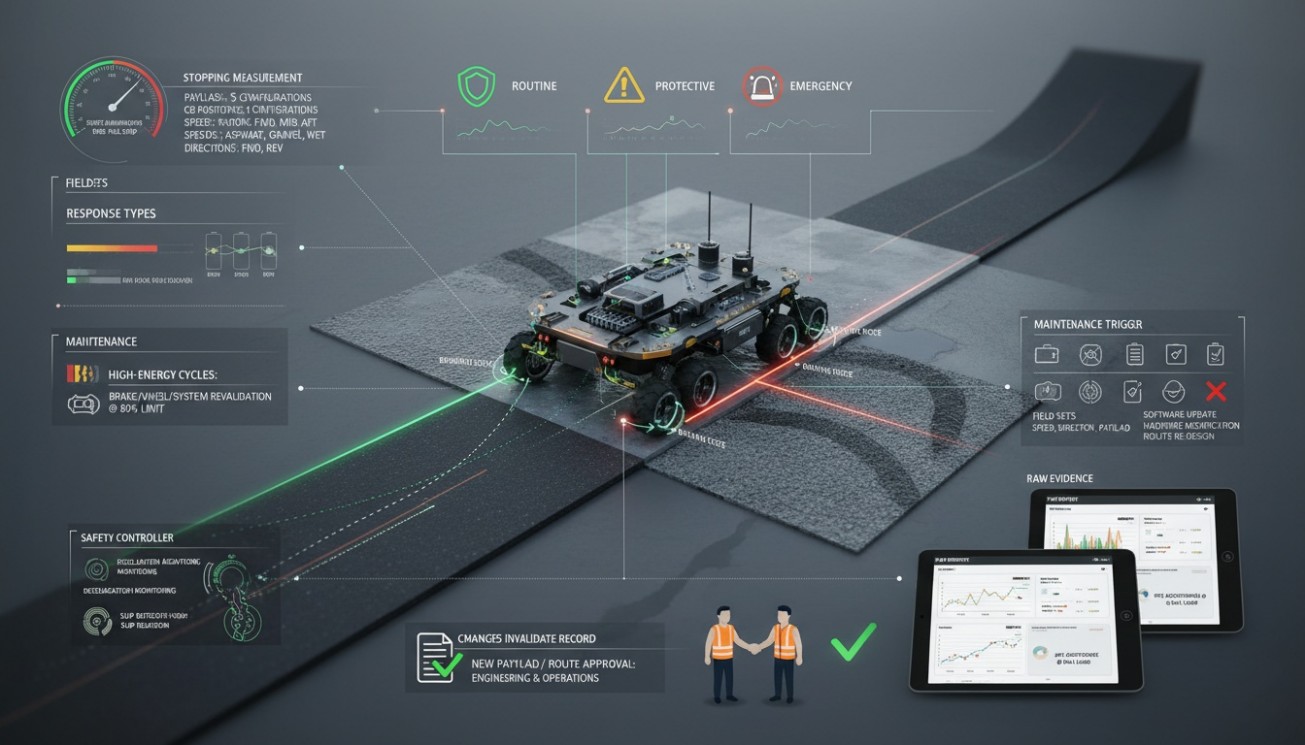
A tape measure at the front bumper is insufficient for a mature program. Useful channels include:
- trigger timestamp and source;
- active field set and safety-controller state;
- commanded and measured longitudinal speed;
- brake or torque-command onset;
- longitudinal and lateral acceleration;
- yaw rate and heading change;
- individual wheel speed or slip indicators;
- stop position and contour clearance;
- load displacement, sway or restraint state;
- brake, motor, drive and tire temperatures where relevant.
The measurement definition must state when timing starts and when the stop is considered complete. A low encoder threshold, a full standstill confirmation and a payload-settled condition are not equivalent. Ambiguity can make two suppliers appear different even when their physical behavior is similar—or make unsafe variation disappear inside a convenient definition.
Step 4: Repeat enough to see variation
Do not select the best run. Plot the distribution. Investigate the longest events and any clusters associated with direction, temperature, floor patch, load placement or field transition. The acceptance method should be agreed before data is collected and should address measurement uncertainty. Averages are useful for process understanding; they are rarely sufficient alone for a boundary intended to prevent contact.
Step 5: Test faults and recovery
Verify credible abnormal conditions identified by the risk assessment: loss of commanded deceleration, wheel slip, field obstruction, localization degradation, communications loss, wrong payload class, released restraint, failed station handshake or unauthorized route entry. The aim is not to stage every imaginable failure. It is to prove that foreseeable faults move the system to a controlled state and that operators have a safe, unambiguous recovery method.
Acceptance Criteria Should Describe an Envelope, Not a Demonstration
A purchase specification that says “robot shall stop safely” is not testable. One that says “braking distance shall be 800 mm” may still be incomplete if it omits speed, trigger definition, surface, payload, direction, temperature, turn state and uncertainty.
A stronger requirement has the following structure:
For configuration C-07 carrying payload family P-03 at the maximum authorized combined CG, on route class R-02 at speed zone S-04, the defined protective-stop trigger shall bring the complete configured contour to the required safe state within the approved boundary under the specified surface, slope and component conditions. Evidence shall include synchronized raw traces, repeated results, load-stability observations and the predefined pass/fail method.
This wording does not prescribe a universal number. It forces the project to connect the number to a reproducible condition. The heavy-payload AMR buying guide recommends building acceptance into procurement; the stop-envelope record is the detailed evidence object that makes such acceptance defensible.
What the acceptance report should preserve
- requirement identifier and risk-control relationship;
- tested configuration and authorized equivalence range;
- route, floor, slope, payload and environmental conditions;
- test procedure, instrumentation and calibration status;
- raw traces, calculated metrics and every valid repetition;
- deviations, anomalies and corrective actions;
- final limit, speed permission and protective-field configuration;
- approvals and the owner of future revalidation.
Seven Failure Patterns That Produce False Confidence

1. Testing empty and extrapolating to loaded
An empty run cannot reveal loaded energy, CG limits, restraint behavior, wheel-load distribution or thermal duty. It may be useful as a diagnostic baseline, but it does not authorize the loaded mission.
2. Treating the scanner field as proof of braking
A field is configured geometry. Stopping is physical performance. The field can be too short, selected at the wrong time, based on an obsolete configuration or measured against the wrong contour.
3. Quoting one distance without the trigger definition
Distance from brake-torque onset will be shorter than distance from field intrusion. Both can be valid metrics, but they answer different questions. The application needs the complete event relevant to risk.
4. Using a clean, level floor as the only surface
A polished demonstration lane cannot represent a dusty production bay, coating transition, steel plate or authorized ramp. If the route condition cannot support the required stop, improve the floor, reduce speed, change the route or redesign the control. Do not hide the mismatch inside a generic margin.
5. Averaging away the tail
Ten short stops and one long stop do not become safe because the mean looks attractive. The outlier may reveal a repeatable field-switching race, warm component, wheel unloading or localized floor issue.
6. Assuming the emergency function is always shortest
Different functions can use different control paths and safe-state logic. A harsher command can also create slip or load instability. Measure and validate each claimed response.
7. Never testing again after launch
Wheel compounds change, brakes wear, software is updated, loads become taller, routes move and floors are repaired. Without management of change, an old report can remain administratively valid while its physical assumptions have disappeared.
Lifecycle Control: Keep the Stop Envelope True
The most mature stopping program is not the one with the thickest commissioning report. It is the one that detects when production is drifting away from the approved envelope.
Trend operational stop signatures
Where the safety architecture and data policy allow, monitor response time, deceleration, stop duration, intervention frequency, wheel slip indicators and relevant temperatures. Operational data is not automatically a safety validation, but it can identify drift and select vehicles or routes for inspection. A rising stop-time trend should trigger investigation before it consumes the design allowance.
Define revalidation triggers
Revalidation should be considered after changes to:
- payload family, mass, CG, restraint or overhang;
- top module or chassis structure;
- wheel, tire, brake, drive, suspension or battery specification;
- safety controller, motion software or field configuration;
- authorized speed, route, grade or traffic interaction;
- floor coating, repair, drainage or contamination controls;
- maintenance limits or inspection intervals.
This lifecycle logic aligns with A3 R15.08 Part 3’s emphasis on management of change during use. It also converts maintenance from a calendar-only activity into preservation of a verified safety outcome.
Give every limit an owner

The manufacturer owns evidence and limits for the supplied vehicle. The integrator owns configured-system behavior and application integration within its scope. The user owns the operating environment, authorized loads, maintenance, traffic rules and changes after handover. Contract boundaries differ, but no assumption should be ownerless. If nobody is accountable for floor friction, payload variation or field changes, the stop envelope will eventually become fiction.
Procurement Questions That Reveal Engineering Maturity
- What exactly starts and ends your published stopping measurement?
- Which payloads, CG positions, speeds, surfaces, slopes and directions does the value cover?
- Do you provide separate data for routine, protective and emergency responses?
- How does your safety controller monitor deceleration or detect inadequate stopping behavior?
- Which wheels generate braking force, and how is wheel slip managed?
- How are curved-path and reverse stops validated?
- What happens to stopping performance after repeated high-energy cycles?
- What maintenance limit triggers brake, wheel or system revalidation?
- How are field sets tied to speed, direction and payload configuration?
- What raw evidence will be delivered with FAT and SAT?
- Which changes invalidate the original test record?
- Who approves new payloads or route speed changes after commissioning?
A credible supplier may not answer every question with one existing chart. That is acceptable. The maturity signal is whether the team can define assumptions, propose a defensible test and state what the evidence will and will not prove.
Focused FAQ
Does a heavier AMR always take longer to stop?
Not necessarily in the ideal constant-deceleration model: if initial speed and effective deceleration are identical, mass cancels from the distance equation. In real machines, greater gross mass increases brake energy and can change temperature, torque limits, wheel loads, traction, CG behavior and allowable deceleration. That is why mobile robot stopping distance must be measured for the authorized configuration and condition rather than inferred from mass alone.
Why does speed matter more than many buyers expect?
Distance traveled during a fixed response delay increases approximately linearly with speed, while ideal braking distance increases with speed squared. A modest speed increase can therefore require a much longer field and can make an intersection or narrow aisle unsuitable.
Can a supplier’s catalog braking value be used directly for safety-field design?
Only if the supplier’s definition, vehicle configuration, payload, speed, surface, direction, test state and uncertainty cover the actual application—and the application risk assessment accepts that evidence. In most projects it is a useful input, not the complete answer.
What is the difference between braking distance and total stopping distance?
Braking distance begins when effective deceleration starts. Total stopping distance also includes travel during sensing, logic, communications and drive response before that deceleration. Protective-field design needs the complete relevant system response plus justified geometry and allowances.
Should an AGV be tested on a wet or oily floor?
Only if that condition is authorized or reasonably foreseeable under the application’s risk controls, and only through a controlled, safe test plan. If wet or oily operation is prohibited, the site needs detection, housekeeping, access control and recovery rules that make the prohibition real. Testing should represent the lowest-friction condition the operation actually permits.
How is an autonomous platform different from a conventional AGV in this topic?
The physics of stopping still applies. Differences arise in sensing, path planning, field switching, motion modes and system responsibility. An autonomous mobile robot stopping distance assessment may need to examine replanned curves and dynamic speed zones, while an AGV stopping distance assessment may focus more heavily on fixed-path zones. Neither label removes the need to validate the configured machine.
What data should be retained from a stopping test?
Retain configuration identity, payload and CG, surface and slope, trigger event, active field and controller states, commanded and measured speed, time histories, stop position, yaw, load behavior, temperature where relevant, every repetition, anomalies, uncertainty, acceptance decision and approvals.
How often should stopping performance be revalidated?
There is no universal interval for every application. Establish an interval from risk, duty, component wear and manufacturer instructions, then add event-driven checks after relevant changes, abnormal stops, collisions, floor modifications, brake or wheel work, software changes and observed drift. An AGV braking performance trend can help target inspections but does not replace the defined validation procedure.
Final Perspective: Authorize a Stop Envelope, Not a Number
Stopping performance is where a heavy-payload chassis, its load and the factory floor become one physical system. A scanner detects; a controller decides; a drive responds; brakes and wheels generate force; the floor accepts that force; the chassis decelerates; the payload reacts; and the application either reaches a safe state or does not.
The best engineering model therefore separates response travel from braking travel, recognizes the squared effect of speed, treats mass through real energy and force limits, and validates grade, curves, friction, CG, temperature, wear and configuration change. A serious AGV stopping distance claim is not a marketing number. It is a traceable boundary supported by reproducible evidence.
That evidence should govern speed zones, protective fields, route permissions, load families, maintenance limits and revalidation. When the stop envelope is explicit, procurement becomes clearer, safety fields become defensible and throughput decisions can be made without borrowing margin that does not exist. When it is vague, the system may appear safe only because its assumptions have never been tested together.
Engineering Evidence Notes
- ISO 3691-4:2023 is the current published international standard for safety requirements and verification of driverless industrial trucks and their systems; its public scope includes AGVs and AMRs and notes the significance of operating-zone condition.
- ISO/DIS 3691-4, Edition 3 was in the enquiry stage as of August 2026. It is a draft under development, not a replacement published standard.
- A3’s official robot-safety standards page identifies R15.08 Part 1 for the individual IMR and Part 2 for IMR systems and applications; A3’s store records Part 3 for user operation and lifecycle risk control.
- SICK’s protective-field engineering article describes vehicle stopping distance as braking travel plus distance covered during safety-scanner and safety-control response, and identifies brake type, environment, load, direction and wheel condition as relevant variables.
#HeavyPayloadAMR #AMRStoppingDistance #AGVStoppingDistance #AMRBrakingDistance #MobileRobotSafety #AMRSafetyField #EmergencyStop #AGVValidation #BrakeTesting #IndustrialMobileRobots #ISO36914 #DynamicStabilit

