Heavy-Payload AMR Traction: Turning Motor Torque into Usable Floor Force
Motor Torque Is Not the Same as Usable Traction
A heavy mobile robot can have large motors, high-ratio gearboxes and an impressive payload label yet still struggle to launch on a ramp, hold a curve, cross a polished patch or repeat the same mission for an entire shift. The reason is simple: torque is produced inside the drivetrain, but useful motion is created at the wheel-floor contact patch. Everything between those two points can limit the result.
The engineering question is therefore not, “How much torque does the motor make?” It is, “How much controlled force can the configured vehicle transmit to the actual floor, in the required direction, for the required duration, without unacceptable slip, heat, instability or load movement?” That is the central question behind heavy payload AMR traction.
This article develops a practical Traction Budget for industrial buyers, integrators and chassis engineers. It connects wheel torque, driven-wheel normal load, floor adhesion, rolling resistance, grade, acceleration, turning demand and duty cycle. It also explains why a vehicle can be motor-limited in one mission, adhesion-limited in another and thermally limited after repeated cycles.
The site’s existing heavy-payload chassis drive-type guide compares differential, steering, omnidirectional and Mecanum layouts as architecture choices. This article begins one level deeper. It treats the selected architecture as a force-distribution system and asks whether the whole configured machine can convert torque into repeatable production motion.
The Traction Budget: Five Ledgers Must Close at the Same Time

A catalog specification usually presents isolated values: rated payload, motor power, maximum speed and maximum grade. A production vehicle is governed by their interaction. A useful engineering review should close five ledgers at the same operating point.
- Demand ledger: the force required to accelerate the gross mass, overcome rolling resistance, climb or descend the route and execute the commanded turn.
- Torque ledger: the wheel force theoretically available from the motor, gearbox, transmission efficiency and effective rolling radius.
- Contact ledger: the force the driven contact patches can transmit before slip, based on local wheel load, wheel material, surface condition and direction of force.
- Thermal ledger: the force that can be repeated over the real duty cycle without exceeding motor, drive, gearbox, brake or tire temperature limits.
- Control ledger: the force that the controller can allocate among wheels while maintaining the requested path, yaw response, stability margin and load restraint.
The usable answer is not the largest number in those ledgers. It is the smallest credible limit after uncertainty and application constraints are considered. In compact form:
usable drive force = min(torque capability, contact capability, thermal capability, control capability)
That available force must remain greater than route demand with an application-specific margin. This is the governing logic for AMR traction force. It also explains why adding a larger motor does nothing when the driven wheels have already saturated, and why a high-friction wheel compound can create a new gearbox, steering or floor-wear problem if the rest of the system was not designed for it.
The Traction Conversion Chain

Traction should be traced as a conversion chain, not treated as a single component rating:
battery voltage and current → motor torque-speed point → gearbox output torque → wheel torque → contact-patch force → vehicle acceleration
Each arrow has losses, limits and measurement uncertainty. Battery voltage can sag during a high-current launch. A controller can limit phase current. A motor can supply peak torque for seconds but not continuously. Gearbox efficiency varies with operating point and temperature. A compliant polyurethane tire changes effective rolling radius under load. Finally, the floor can refuse the force through slip.
From motor torque to theoretical wheel force
For a screening calculation, wheel torque can be estimated as:
Twheel = Tmotor × i × η
where i is the reduction ratio and η is the combined drivetrain efficiency at the operating point. The theoretical tangential force at one wheel is:
Fwheel = Twheel / reffective
This is necessary for AGV motor sizing, but it is not sufficient. The value is only a torque-side ceiling. It does not prove that the floor can accept the force, that all driven wheels carry equal normal load or that the drivetrain can sustain the torque over a production cycle.
Use the loaded effective rolling radius, not only the unloaded catalog radius. Tire compression, wear and temperature can change that radius and therefore change force, speed and encoder-based distance estimates. For a multi-wheel vehicle, do not multiply one wheel’s force by the number of motors until torque limits, gearbox ratios, wheel radii, wheel loads and control allocation have been confirmed for every driven position.
From wheel torque to floor-transmitted force
A simple adhesion screen for a driven wheel is:
Fadhesion,max,i ≈ μa,i × Ni
Here, μa,i is an application-specific adhesion coefficient and Ni is the instantaneous normal force on that driven wheel. The sum of these limits is not automatically available in every direction. Steering angle, Mecanum roller geometry, lateral demand, wheel compliance and force allocation change the usable vector.
The coefficient must come from representative wheel and floor conditions. It is not a universal property of “polyurethane on concrete.” Surface finish, dust, oil, moisture, coatings, curing, wheel hardness, contact pressure, wear and temperature all matter. A supplier table is useful for early screening, but route evidence is required for approval.
Most importantly, adhesion coefficient and rolling-resistance coefficient are different quantities. Adhesion limits how much tangential force can be transmitted before slip. Rolling resistance describes the force consumed by deformation and losses during travel. Using one as the other can make an otherwise polished calculation physically meaningless.
Build the Demand Side Before Selecting the Drive

The drive should be sized against a mission envelope, not a single maximum-load event. For straight-line screening on a uniform slope, the required floor force can be organized as:
Frequired = m a + Crr m g cos(θ) + m g sin(θ) + Fauxiliary
The terms represent acceleration, rolling resistance, grade and additional application forces. Additional forces may include a towed cart, cable drag, a transfer mechanism contacting a station, steering scrub, seal drag or another measured resistance. The equation is a design screen, not a substitute for configured-vehicle testing.
Acceleration demand
The inertial term is m a, where m is gross moving mass: base vehicle, battery, top module, fixture, carrier, payload and any attached equipment. Using payload mass alone understates demand. A 1,500 kg payload on a 900 kg configured vehicle is a 2,400 kg moving system before accessories or towed equipment are added.
Acceleration is also not just a productivity setting. It changes wheel-load transfer, load-restraint demand, yaw response and peak electrical current. A motion profile with a smooth velocity trace can still contain sharp jerk at segment transitions. Those short events can excite fixture clearance, wheel compliance or gearbox backlash and produce momentary slip that an average-current plot hides.
Rolling resistance is a route variable
The term Crr m g cos(θ) is often treated as a small constant. In real factories, mobile robot rolling resistance changes with wheel compound, tire deflection, floor roughness, joints, debris, bearing condition, caster alignment and load. A polished test lane may produce a very different value from an old production aisle with repaired cracks and steel covers.
Rolling resistance is an energy consumer even when adhesion is abundant. It raises continuous motor torque and battery power, increases heat and reduces available margin for a grade or acceleration. A route survey should therefore connect surface segments to measured or defensibly estimated resistance rather than assigning one ideal value to the entire facility.
Grade demand does not disappear at low speed
The gravity term is m g sin(θ). It applies whenever the vehicle is on a grade, including a low-speed launch. At small angles it may appear modest, but gross mass makes it significant. Grade also changes load distribution and can combine with longitudinal center-of-gravity offset, braking, turning or a transition between level floor and ramp.
A published “maximum grade” is incomplete unless it states vehicle configuration, payload and center of gravity, travel direction, surface condition, entry geometry, speed, allowable duration and whether the vehicle can restart from rest. AGV gradeability must be treated as an operating-envelope claim, not a single percentage.
Power becomes the ceiling at speed
At the contact patch, mechanical power is approximately:
Pfloor = F × v
A drive may provide high force at low speed but become power-limited as speed rises. Conversely, a motor with adequate rated power can lack the low-speed continuous torque or thermal path required for repeated loaded starts. A complete torque-speed curve and duty-cycle model are therefore more useful than one motor power number.
Three Different Failures Can Look Like “Not Enough Motor”
When a robot slows, stalls, deviates or fails a ramp, teams often request a larger motor. Before changing hardware, classify the governing limit.
Torque-limited behavior
The commanded wheel force exceeds available motor or gearbox output. Current reaches its limit, wheel speed falls, but the contact patch remains below its slip boundary. Possible causes include insufficient reduction, excessive wheel radius, underestimated rolling resistance, voltage sag, controller limits or an incorrect continuous-torque assumption.
Adhesion-limited behavior
The motor and gearbox can request more force than the contact patch can transmit. Wheel rotational speed rises relative to vehicle speed, current and yaw behavior may oscillate, and path or localization error can grow. More peak torque can make the event worse. The remedy may involve driven-wheel load, wheel material, suspension equalization, motion-profile limits, floor control or torque allocation.
Thermal- or system-limited behavior
The vehicle completes one run but cannot repeat it. Motor winding, inverter, gearbox, brake or tire temperature rises; control derating begins; lubrication losses change; or battery voltage falls. A proof run demonstrates immediate capability, not production capability. The relevant evidence is a representative cycle repeated until temperatures and performance stabilize—or until the defined test limit is reached.
This classification is a practical diagnostic tool for a heavy duty AMR drive system. It keeps teams from solving a contact or duty-cycle problem by oversizing one electrical component.
Driven-Wheel Load Is the Missing Variable in Many Payload Calculations
Total mass tells engineers the total gravitational force. It does not tell them how much normal load reaches each driven wheel. The distinction is fundamental because non-driven casters and support wheels can carry mass without creating propulsion.
Static distribution is only the starting point
Measure or calculate corner reactions for the complete configuration: empty vehicle, nominal payload and worst permitted center-of-gravity positions. Do not assume total mass divided by wheel count. Top-module offset, battery placement, frame deflection, suspension preload and floor levelness can create unequal reactions even when the nominal payload appears centered.
The phrase AGV drive wheel load should refer to the normal reaction at each driven contact under a defined condition—not the supplier’s structural wheel-capacity label. A wheel may be structurally rated to carry 700 kg yet carry only 250 kg of normal load in the configured vehicle. For traction, the latter is the relevant value.
Dynamic transfer changes the contact budget
Acceleration, braking, slope and lateral acceleration transfer load among wheels. A high combined center of gravity magnifies the change. A rigid frame on an uneven floor may unload a corner. A compliant suspension can preserve contact but introduce deflection and load-sharing dynamics that must be characterized.
Dynamic transfer matters even when the vehicle remains far from rollover. One lightly loaded drive wheel can saturate first, triggering slip, yaw error or controller intervention while the other wheels still have unused capacity. The early limit is local, not global.
Wheel load is also a structural and lifecycle input
More driven-wheel preload can improve available adhesion, but it is not free. It can increase tire deformation, bearing load, floor point load, rolling resistance and heat. The objective is controlled load distribution within structural, thermal, floor and wear limits—not simply the maximum possible normal force on the drive wheel.
Buyers who need the broader relationship between configuration, route and rated capacity should use the site’s heavy-payload chassis engineering overview as the cluster-level starting point.
How Drive Architecture Changes Force Allocation
Every architecture obeys the same contact physics, but each distributes demand differently. The following is not another feature comparison. It is a review of where traction margin is created or consumed after an architecture has been selected.
Differential drive: protect the driven-mass fraction

A typical differential platform controls longitudinal force and yaw moment through left-right wheel force. It is mechanically compact and can turn in place, but its usable traction depends heavily on how much gross weight rests on the driven wheels.
Passive casters can carry a large share of the load. Load offset, ramp attitude or an uneven joint can further unload one drive wheel. During a pivot, tire scrub and caster swivel resistance can make force demand much higher than straight-line rolling demand. A vehicle that starts easily in a straight line can therefore current-limit, slip or twist during a loaded zero-radius turn.
Validation should measure left and right wheel reactions, current and wheel-speed mismatch during straight launches, curves and pivots. Motion control should limit yaw acceleration according to payload and surface condition rather than treating a pivot as a purely kinematic command.
Steered drive: align force before demanding force
A steered drive can align the wheel plane with the desired travel direction, reducing some scrub compared with skid steering. However, steering angle, steering rate and drive torque must be coordinated. Applying high propulsion torque before the wheel reaches its commanded angle can create side force, tire deformation and path error.
Heavy loads also increase steering-actuator and bearing demand. When multiple steered drive units are used, small angle or radius mismatches can make the units fight each other. The result may appear as high rolling resistance, motor heating or floor marking even though each module passes an isolated bench test.
For this architecture, the evidence package should include steering accuracy under load, synchronization during mode changes, drive-force allocation, transient current, tire temperature and behavior when one wheel crosses a lower-friction surface.
Omnidirectional drive: available force is directional
An omnidirectional platform transforms individual wheel forces into longitudinal, lateral and yaw motion. That transformation provides valuable maneuverability, but commanded chassis force is not equal to the arithmetic sum of motor forces. Roller angle, wheel arrangement, contact compliance and simultaneous yaw demand affect the contribution of each wheel.
Research on omnidirectional mobile robots describes dynamic anisotropy: acceleration and torque demand can vary with direction. In practice, omnidirectional AMR traction must be tested across the directions the application actually uses, not only forward travel. Lateral translation, diagonal motion and translation-plus-rotation can have different force, loss and slip behavior.
Unequal wheel load is especially important because one saturated wheel can corrupt the intended force vector. More controller authority cannot create adhesion that the contact patch lacks. A strong design combines mechanical load equalization, calibrated wheel radii, coordinated current control and motion limits that reflect floor condition and payload state.
None of this means omnidirectional motion is inherently unsuitable for heavy loads. It means maneuverability must be purchased with evidence: directional force capacity, thermal behavior, wheel-load distribution, floor compatibility and repeatability. The correct answer depends on the application envelope, not a universal ranking of drive types.
Turning Uses the Same Contact Capacity as Propulsion
A wheel-floor interface has limited capacity to transmit combined longitudinal and lateral force. Vehicle-dynamics texts often visualize this as a friction circle or ellipse. Industrial polyurethane wheels, casters and Mecanum rollers do not behave exactly like pneumatic road tires, but the systems principle remains useful: force used to generate or resist lateral motion is not simultaneously available for unlimited acceleration or braking.
This matters in three common events:
- accelerating while exiting a curve;
- protective stopping while turning;
- climbing a ramp that includes a curve or cross-slope.
A straight-line pull test cannot approve those combined cases. The controller should manage the vector demand, and the validation plan should include the route’s worst credible combinations. When slip occurs, it can affect more than propulsion: encoder odometry, docking approach, yaw control, safety-field alignment and load stability may all be affected.
A Worked Screening Example: Same Vehicle, Two Contact Conditions
The following example is illustrative. It is intended to show calculation structure, not to claim a permissible speed, grade or safety margin for any product. Final values must come from the configured machine, representative floor and project risk assessment.
Assumed configuration
| Input | Illustrative value | Why it matters |
|---|---|---|
| Gross moving mass | 2,050 kg | Includes base, battery, module, fixture, carrier and payload |
| Target acceleration | 0.50 m/s² | Creates inertial force and load transfer |
| Route grade | 3 degrees | Adds gravity demand |
| Rolling-resistance coefficient | 0.020 | Illustrative route screen, not an adhesion value |
| Normal load on driven wheels | 60% of gross weight | Defines the contact-force ceiling for driven positions |
| Wheel radius | 0.125 m | Converts torque to force |
| Four motor continuous torque | 12 N·m per motor | Illustrative continuous operating point |
| Reduction and efficiency | 12:1 and 0.85 | Converts motor torque to wheel torque |
Step 1: calculate route demand
Acceleration force is approximately 2,050 × 0.50 = 1,025 N. Grade force is approximately 2,050 × 9.81 × sin(3°) = 1,052 N. Rolling force is approximately 0.020 × 2,050 × 9.81 × cos(3°) = 401 N.
The screened straight-line demand is therefore about 2,478 N before steering losses, joint impact, uncertainty, auxiliary forces or a project margin are added.
Step 2: calculate the torque-side ceiling
Each motor produces an illustrative continuous wheel torque of 12 × 12 × 0.85 = 122.4 N·m. At a 0.125 m rolling radius, that is about 979 N per wheel, or 3,917 N across four equally contributing wheels.
This does not yet prove that 3,917 N is usable. It only closes the torque ledger at the assumed point.
Step 3: calculate two adhesion screens
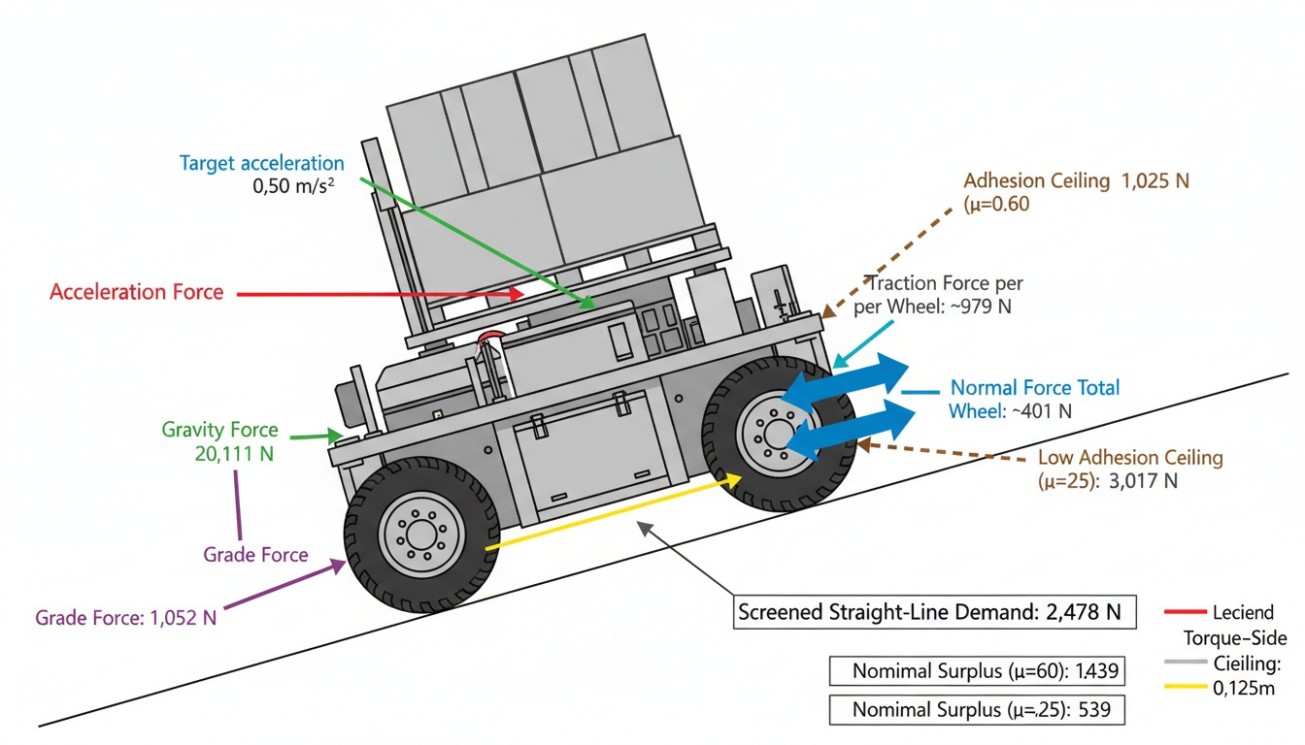
The driven-wheel normal load is approximately 2,050 × 9.81 × 0.60 = 12,066 N.
With an illustrative adhesion coefficient of 0.60, the contact-side ceiling is about 7,240 N. The continuous system is therefore torque-limited at about 3,917 N before other constraints. The nominal surplus over the 2,478 N straight-line demand is about 1,439 N.
With an illustrative low-adhesion coefficient of 0.25, the contact-side ceiling falls to about 3,017 N. Now the same hardware becomes contact-limited, leaving only about 539 N before uncertainty, steering demand or local wheel-load variation. A single lightly loaded or contaminated wheel could consume that apparent margin.
This is a compact AGV traction calculation, not an approval. It shows why a torque-rich design can become adhesion-limited without any hardware fault, and why a result based on a mean coefficient and perfectly equal wheel loads can still be optimistic.
Step 4: check power and duration
At 1.2 m/s, the screened floor power for the 2,478 N demand is about 2.97 kW. Electrical input must be higher because motor, inverter, gearbox and tire losses remain. If the grade is long or launches are frequent, RMS torque and temperature can govern even though the short calculation passes.
The result should therefore be expressed as an operating point with assumptions, not as “the vehicle can climb 3 degrees.” It has not yet addressed curve demand, restart after a stop, reverse travel, battery state, thermal equilibrium, wear or fault recovery.
Why Slip Is a System Event, Not Just a Tire Event
AMR wheel slip occurs when commanded or wheel-implied motion differs materially from vehicle motion at the contact interface. Slip can be longitudinal, lateral or a combination. It can be brief and local, or it can become a sustained loss of control authority.
Potential symptoms include wheel-speed divergence, unexpected motor current, yaw-rate error, encoder-to-localization disagreement, path correction, floor marking, oscillatory torque commands or failed docking. No single signal is definitive in every architecture. For example, wheel-speed difference is expected during a differential turn and must not be mistaken for slip.
A diagnostic strategy can compare commanded chassis motion with wheel encoders, motor current, inertial measurement, steering angle and an independent velocity or localization estimate. Thresholds should account for maneuver type, wheel compliance and sensor uncertainty. A production diagnostic is not automatically a safety function; any safety-related use requires the appropriate safety architecture, validation and standards assessment.
Slip also changes lifecycle economics. Repeated micro-slip can accelerate tread wear, create heat, polish or mark the floor and degrade odometry. A robot can complete missions while its traction margin is slowly disappearing. Trend data is therefore more valuable than a one-time pass/fail observation.
Traction Validation Must Reproduce the Operating Envelope
Validation should progress from low-energy characterization to boundary combinations. It should preserve configuration identity so that results remain traceable to the vehicle that enters production.
Freeze the test article
Record chassis and software revisions, battery configuration, motor and controller versions, gearbox ratio, wheel part number and condition, tire hardness where relevant, suspension settings, top module, fixture, fasteners, gross mass, individual wheel reactions, combined center of gravity and load-restraint method.
If any of those elements changes after the test, engineering should decide whether the evidence still applies. A “same model” label is not enough when the force path or control map changed.
Characterize the floor and route
Identify representative surfaces, coatings, joints, ramps, cross-slopes, drainage covers, contamination states and transition geometry. Measure conditions at the route segments that create the highest demand, not only at the easiest test area. ISO 3691-4:2023 explicitly notes that operating-zone condition significantly affects safe operation; the official scope and current status are available from the ISO 3691-4:2023 page.
The site’s heavy-duty mobile base guide provides additional context for treating route, floor and load as part of one application rather than independent specification rows.
Measure supply, demand and motion together
A useful instrument set may include synchronized wheel speed, motor current or estimated torque, commanded velocity, measured chassis velocity, yaw rate, steering angle, battery voltage, relevant temperatures and event markers. When appropriate and safely engineered, drawbar force or an instrumented grade test can help characterize force capability.
Measurement uncertainty, sample rate, signal alignment and calibration must be documented. A graph without a common time base can hide whether current rise preceded slip, followed a joint impact or resulted from control correction.
Use a scenario matrix, not one maximum-load run
At minimum, consider:
- empty, nominal and maximum permitted mass;
- low-centered and worst permitted center-of-gravity configurations;
- forward, reverse and application-relevant lateral directions;
- straight acceleration, curve entry, curve exit, pivot or steering-mode transition;
- level floor, representative grade and grade transition;
- high- and low-adhesion route segments;
- cold start and thermally stabilized operation;
- new and service-limit wheel conditions;
- normal mission, protective stop and defined recovery behavior;
- repeated cycles representing production frequency.
Acceptance criteria should be project-specific and measurable: allowed speed error, slip duration, path error, current limit behavior, temperature limit, restart capability, load movement, docking result and recovery action. Do not borrow an arbitrary universal success percentage from another application.
Separate capability, control and safety evidence
A traction test can show that the vehicle develops force. A control test can show that it follows the intended motion without unacceptable slip or yaw error. A safety validation addresses risk-reduction functions and the configured application. These evidence classes support one another but are not interchangeable.
For the U.S. standards context, the current A3 bundle describes Part 1 as requirements for the individual IMR, Part 2 as requirements for IMR systems and applications, and Part 3 as requirements for continued safe use. The scopes and 2026 publication status are summarized on the official ANSI/A3 R15.08 Parts 1, 2 and 3 page. Applicable editions and local requirements should be confirmed for each project.
What Buyers Should Request Instead of a “High-Torque Motor” Claim

A strong supplier response connects component data to a configured operating envelope. Procurement can ask for a Traction Evidence Package containing:
- gross-mass and center-of-gravity limits for each approved payload family;
- individual static wheel reactions and the method used to establish them;
- motor torque-speed curves, controller current limits and battery-voltage assumptions;
- gearbox ratio, efficiency basis, permissible output torque and thermal derating;
- loaded wheel radius, wheel material, wear limit and replacement criteria;
- rolling-resistance assumptions tied to representative route conditions;
- adhesion test method and boundary surface conditions;
- grade capability stated by load, direction, speed, duration and restart condition;
- force-allocation and slip-response behavior for the selected drive architecture;
- instrumented test records for nominal, boundary and repeated-duty scenarios;
- configuration-controlled acceptance limits and revalidation triggers.
Oriental Motor’s official AGV sizing tool, for example, asks for vehicle mass, wheel diameter, rolling-friction coefficient, system efficiency, floor slope and operating conditions before producing torque results. That input structure is a useful reminder that a motor cannot be sized from payload alone. It is still a component-sizing aid, not configured-vehicle acceptance evidence.
Procurement teams can combine this traction package with the site’s heavy-payload AMR procurement and acceptance guide. Safety responsibilities, protective fields, traffic rules and load behavior should also be aligned with the heavy-payload AMR safety and risk-assessment guide.
Change Control: The Approved Traction Budget Can Move
Traction evidence has a configuration and an environment. It does not remain true automatically for the life of the fleet. Reassessment may be needed after:
- a wheel compound, hardness, diameter or supplier change;
- a caster, suspension, bearing or preload change;
- a motor, gearbox, controller, battery or torque-map revision;
- a top-module, fixture, carrier, payload or center-of-gravity change;
- a higher acceleration, speed, route grade or production frequency;
- a floor coating, repair, contamination regime or washdown process change;
- a software update that changes motion planning, torque allocation or slip response;
- wear data or field events that show drift toward an acceptance boundary.
The operational owner should know which changes can be released by maintenance instruction, which require engineering review and which require partial or full revalidation. This lifecycle logic prevents a vehicle from operating on an envelope that existed only on commissioning day.
A Decision Rule for Engineering Reviews
For every critical mission segment, document one row in a Traction Budget:
- define the configuration and route condition;
- calculate force and power demand;
- establish motor- and gearbox-side capability;
- establish driven-wheel contact capability by direction;
- apply thermal, control, stability and load-restraint limits;
- identify the governing limit and remaining margin;
- validate the boundary with synchronized evidence;
- attach change-control triggers to the approved row.
If a supplier can state only payload, motor power and nominal grade, the traction model is incomplete. If the supplier can show force demand, corner reactions, torque-speed limits, floor assumptions, directional allocation, repeated-cycle temperature and configured test data, the discussion has moved from catalog selection to engineering evidence.
Focused FAQ
Does a larger motor always improve heavy-payload AMR traction?
No. A larger motor improves the torque-side ceiling only if the controller, gearbox, battery and thermal path can use it. If driven wheels are already at their adhesion limit, more torque increases slip risk rather than usable acceleration. First identify whether the vehicle is torque-, adhesion-, thermal- or control-limited.
How is usable traction calculated for an AMR or AGV?
Screen the wheel force from motor torque, gear ratio, efficiency and loaded wheel radius. Separately screen contact capacity from the adhesion coefficient and instantaneous normal load on each driven wheel. The lower credible value is available to meet acceleration, rolling resistance, grade and other route demands. Configured testing is then needed because coefficients, load sharing and losses vary.
Why can a fully loaded robot slip even when total mass increases?
Added mass increases both route demand and total normal force, but the useful normal force may not reach the driven wheels. A top module or payload offset can place more load on passive supports, and dynamic transfer can unload one drive wheel. Local saturation can occur before the total vehicle appears close to a theoretical limit.
Is differential drive better for traction than an omnidirectional drive?
There is no universal winner. Differential drive can be efficient and mechanically simple, but its driven-mass fraction and pivot scrub matter. Omnidirectional drive offers lateral mobility, but force capacity is directional and depends on roller geometry, load equality and multi-wheel allocation. Compare both against the same payload, route, floor, motion and duty-cycle envelope.
What should a gradeability specification include?
It should identify the complete vehicle configuration, payload and center of gravity, surface condition, travel direction, grade and transition geometry, speed, duration, battery condition and whether restart from rest is required. It should also distinguish a short peak event from continuous operation and include stopping or holding behavior where relevant.
How can a fleet detect loss of traction?
Diagnostics can compare commanded motion with wheel encoders, motor current, steering angle, inertial data and an independent velocity or localization estimate. The logic must distinguish normal kinematic differences from actual slip. Diagnostic detection should not be represented as a safety-rated function unless it is engineered and validated as one.
When should traction be revalidated?
Review evidence after changes to wheels, suspension, drive hardware, batteries, software torque maps, top modules, fixtures, payloads, routes, floors, speed profiles or duty cycles. Revalidation is also justified when wear trends, temperature drift, repeated interventions or slip events approach the approved limits.
Conclusion: Approve a Traction Envelope, Not a Torque Number
The drivetrain is only one participant in heavy-load motion. Motor torque becomes production value only after the gearbox, wheel, contact patch, vehicle geometry, control system and operating zone agree to transmit it. That agreement changes with load distribution, floor condition, direction, grade, speed, temperature and wear.
A professional review therefore replaces “How powerful is the motor?” with five connected questions: What force does the mission demand? What force can the drivetrain supply? What force can each contact patch transmit? What can be repeated thermally? What can the controller allocate without losing path, stability or load control?
The resulting Traction Budget is more useful than a larger component specification. It reveals the governing limit, makes assumptions visible, creates testable acceptance criteria and provides a lifecycle baseline for change control. That is how a heavy-payload chassis moves from a promising drive package to a defensible industrial operating envelope.
For adjacent selection and implementation topics, see the Heavy-Payload Chassis guide collection.
#HeavyPayloadAMR #AMRTraction #AGVMotorSizing #DriveForceAllocation #WheelSlip #RollingResistance #DriveWheelLoad #AGVGradeability #OmnidirectionalAMR #IndustrialMobileRobots

