Heavy-Payload AMR Load Path: How Forces Reach the Frame, Wheels and Floor
The Payload Number Is Not the Load Path
A payload rating tells a buyer how much mass a platform may carry under defined conditions. It does not explain where the forces enter the machine, which members share them, how the wheel reactions change, or which interface will lose stiffness first. That missing explanation is the AMR load path: the continuous route through which gravity, inertia, transfer forces and floor reactions travel across the configured mobile robot.
For a typical top-load vehicle, the visible downward chain appears simple:
Payload → carrier or fixture → top module → mounting interface → chassis frame → wheel assemblies → floor.
Real operation is more complicated because force flow is bidirectional. Gravity enters from the payload and closes at the floor. Traction begins at the tire-floor contact patch and travels upward through the drive mounts, frame and fixture to accelerate the payload. A conveyor transfer may inject a horizontal force from an external station. A floor joint may inject a short vertical impact from one wheel. Braking and turning create moments because the combined center of gravity is above and may be offset from the support polygon.
This is why a heavy payload AMR should be approved as a named configuration, not as an isolated base with a nominal capacity. The base, battery, wheels, lift, conveyor, fasteners, fixture, carrier, payload, software motion limits and operating floor form one force-transmission system. If any boundary in that system changes, the approved force flow may change with it.
The Force-Flow Map: One Vehicle, Several Directions of Load

The most useful way to review AMR chassis design is not to ask whether the frame “looks strong.” It is to draw a free-body diagram for each important event and mark where force enters, where it changes direction and where it leaves. The following Force-Flow Map separates events that are often collapsed into one payload case.
| Operating event | Primary force entry | Main structural path | Commonly missed demand |
|---|---|---|---|
| Stationary on level floor | Payload and vehicle gravity | Supports → top plate → frame → wheel mounts → floor | Local bearing pressure and unequal corner reactions |
| Longitudinal acceleration | Tire-floor traction | Drive wheel → gearbox mount → frame → fixture → payload | Pitch moment, joint slip and rear/front wheel-load transfer |
| Controlled or protective stop | Braking force at driven or braked wheels | Wheel contact → brake/drive mount → frame → load restraint | Payload restraint demand and transient frame twist |
| Turning | Lateral tire forces | Contact patches → wheel modules → frame → top module → payload | Roll moment, inside-wheel unloading and fixture side load |
| Crossing a joint or step | One or two wheels | Wheel/tire → bearing and mount → local frame → diagonal structure | Impact amplification and torsion from non-coplanar support |
| Conveyor or pallet transfer | External station and transfer actuator | Roller/fork/chain → module frame → mount group → chassis | Side thrust, snag force, partial support and docking deflection |
| Ramp or cross-slope | Gravity resolved along and normal to the floor | Payload → supports → chassis → uneven wheel reactions | Combined slope, CG offset, braking and reduced traction reserve |
The table exposes a central engineering truth: the component carrying the highest load can change during the mission. The rear wheel mounts may dominate during acceleration, the front restraint may dominate during braking, one chassis corner may dominate on an uneven joint, and a small bracket may dominate while a pallet is only partly transferred. Designing only for a uniformly distributed static payload therefore misses the states most likely to reveal a weak interface.
Trace Every Boundary from Payload to Floor
1. Payload to Carrier: Define the Real Contact Pattern
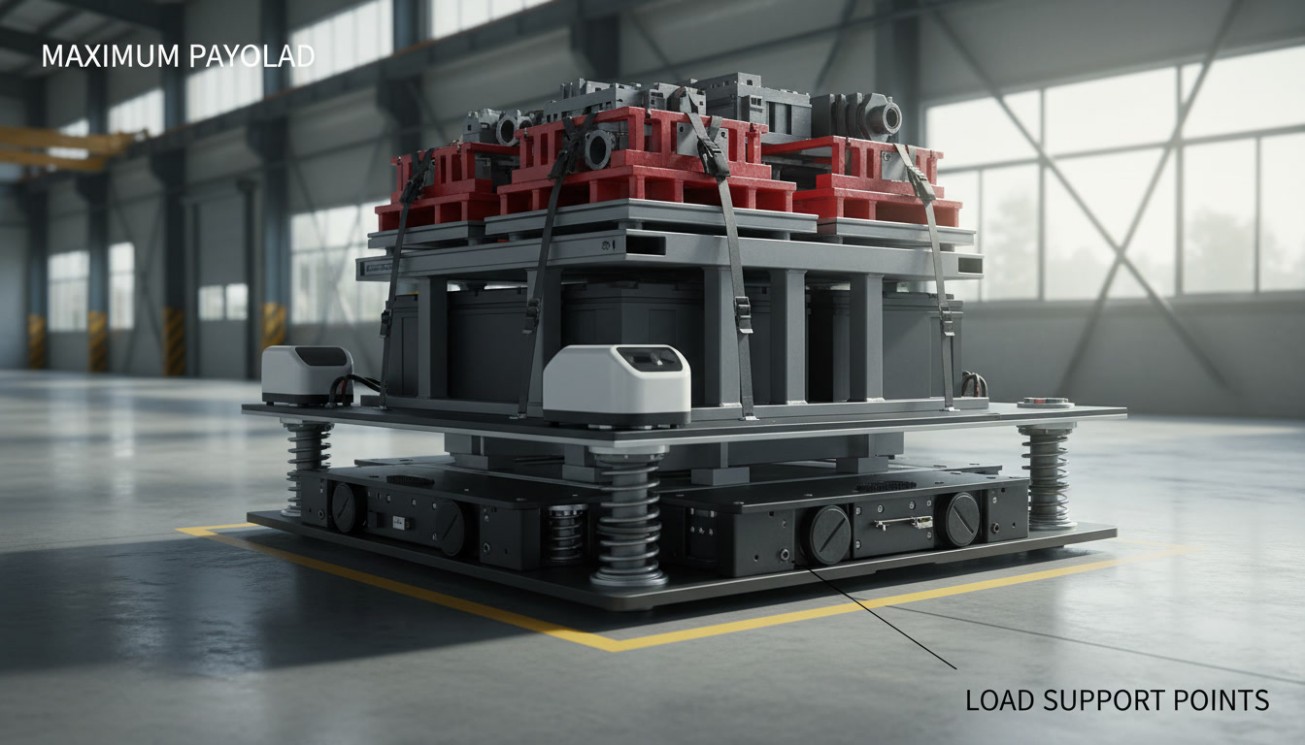
The first boundary is rarely a perfectly distributed pressure. A pallet may contact four blocks. A battery tray may rest on two rails. A casting may touch three locators. A tall rack may enter through narrow feet. Even a large crate can place most of its weight near a reinforced skid rather than across its visible footprint.
Engineering should record the number, location and size of contact points; permissible position error; friction or positive restraint; payload center of gravity; and whether the load can settle, deform or shift. A carrier with four nominal feet can behave like a three-point support if one foot is short. A damaged pallet board can move the contact patch. A liquid, suspended component or loosely packed bin can shift its internal mass after the route has begun.
This boundary determines the initial AMR load distribution. Treating a payload as uniform when it actually enters through two narrow rails can understate local plate bending, fastener demand and frame deflection. The correct input is the verified support geometry of the real production carrier, including its tolerances and worst credible placement.
2. Carrier to Top Module: Support and Restraint Are Different Functions
Vertical support answers, “What carries the weight?” Restraint answers, “What carries braking, turning and transfer forces?” Friction alone may support gentle motion, yet it can be unreliable when surfaces are wet, dusty, worn or contaminated. Positive locating pins, stops, clamps or captured geometry can provide a defined horizontal path, but they also create concentrated forces that must be carried into the module.
An AMR top module may be a passive deck, lift, roller conveyor, fork mechanism, rack lifter, rotating table, robot arm pedestal or custom fixture. Its own mass is part of the vehicle's gross mass. Its center of gravity changes the combined CG. Its frame may bridge over the base in a different direction from the chassis rails. Its actuator can add internal forces far larger than the static cargo weight at a local pin, bearing or screw.
For this boundary, document support locations, restraint directions, maximum gaps, locating repeatability, coefficient-of-friction assumptions, actuator forces, jam or snag loads and the load state during transfer. The worst state may occur with the payload halfway on the robot, not fully seated.
3. Top Module to Base: The Mounting Pattern Is a Structural Interface
The mounting plate is often treated as packaging: find open holes, add an adapter and tighten the bolts. In reality, the AMR top module interface—the controlled mechanical boundary between the module and base—must transmit vertical shear, longitudinal and lateral shear, overturning moments, torsion and local prying without unacceptable slip or deformation.
A bolt's catalog tensile capacity does not describe the whole joint. The joint may depend on clamp preload and friction to prevent slip, on dowels to carry shear, or on bolt bearing after clearance is consumed. Thin adapter plates can dish around fasteners. Tall spacers can magnify bending. Slotted holes simplify assembly but can permit motion unless the joint strategy accounts for them. Welded nuts and threaded inserts can introduce their own local limits.
The interface specification should therefore identify mounting datums, flatness, hole size and position tolerance, fastener grade, tightening method, prevailing-torque or locking features, allowable spacer geometry, permitted joint separation, inspection access and retorque policy. Research on vibration-induced fastener preload loss, including work available through the NASA Technical Reports Server, reinforces why “the bolts were tight at commissioning” is not a lifecycle argument.
4. Mounting Plate to Chassis Frame: Avoid Local Strength Islands
A thick top plate can survive while the cross-member below it bends. A reinforced bracket can push stress into a thin rail. A gusset can lower nominal stress but create a stiff termination and a fatigue-sensitive weld toe. The load path must continue beyond the visible attachment into members that can carry it to the wheel supports.
The designer should identify which beams act in bending, which closed sections carry torsion, which bulkheads distribute wheel reactions and where the load changes direction. Short, direct paths generally reduce deflection and mass. Long cantilevers, abrupt section changes and loads introduced between cross-members increase local demand. Service cutouts, battery doors and cable passages should not interrupt a primary path without replacement structure.
This is where AGV frame design and AMR packaging collide. Sensors, batteries, controllers and service access need space, but removing material from a rail or placing a large opening beside a wheel mount can weaken the very region that closes the force loop. A clean CAD package is not proof that the structure has a clean path.
5. Frame to Wheel Assembly: The Reaction Enters Through a Small Region
The frame does not rest on an abstract rectangle. It is supported through steering bearings, drive housings, suspension pivots, caster plates, axle brackets or wheel-module fasteners. These interfaces see vertical reactions plus propulsion, steering, braking and impact loads. Their stiffness influences wheel alignment, tire contact and localization behavior.
Review bearing life, shaft and hub loads, mounting-plate bending, fastener-group demand, weld details, suspension travel, bump-stop events and service replacement tolerances. A wheel module rated for a vertical load may still have lower allowable side force or moment. A drive assembly may have enough motor torque but insufficient mount stiffness. A caster may shimmy or unload when the frame twists.
Drive architecture also changes the path. Differential, steered and omnidirectional systems introduce force through different contact geometry and mount arrangements. The site's existing heavy-payload chassis drive-type guide is the appropriate companion for motion-layout selection; this article focuses on how the selected layout carries force.
6. Wheel to Floor: Contact Patch, Point Load and Floor Compliance
The floor is the last structural component in the downward chain and the first in the traction chain. Wheel material and diameter influence contact stress, rolling resistance and impact response. Floor flatness changes which wheels carry load. A plate edge, drain cover or expansion joint can apply a sharp local input. A soft coating can deform under sustained point load, while contamination can reduce the tangential force available before slip.
Average pressure based on gross mass divided by vehicle footprint is usually not a useful floor check. The floor sees individual wheel-contact loads over relatively small patches, and those loads vary. Facility evaluation should consider point or patch load, local slab and cover capacity, joint edges, floor finish, friction, transitions and the loaded route. For a broader site discussion, use the internal heavy-duty mobile base engineering guide.
Why Gross Mass Divided by Four Is Usually the Wrong Wheel Load

A four-wheel vehicle with total weight W does not automatically place W/4 on every wheel. Equal reactions require a centered CG, symmetric geometry, equal stiffness, coplanar contact and no acceleration. Production vehicles rarely preserve all of those conditions simultaneously.
For a simplified rigid body on level ground, the reaction sums must satisfy equilibrium:
ΣFz = W, ΣMx = 0, and ΣMy = 0.
If the combined CG is displaced longitudinally, the front and rear axle reactions change with the lever arms to the CG. If it is displaced laterally, the left and right totals change. Under longitudinal acceleration ax, the approximate pitch moment is:
Mpitch = m × ax × hCG.
During a turn with lateral acceleration ay, the approximate roll moment is:
Mroll = m × ay × hCG.
These moments redistribute normal forces. Yet equilibrium equations alone may not determine four individual corner reactions for a stiff four-point support. Chassis torsional stiffness, suspension compliance, tire deformation and floor height variation decide how the remaining load is shared. This makes a realistic AGV wheel load calculation a combined geometry-and-compliance problem, not simple division.
Wheel scales or load cells are valuable because they reveal the configured vehicle's static reactions. Instrumented route testing can then show dynamic peaks. Calculations remain essential for defining cases and interpreting results, but measurement is the fastest way to expose an unmodeled diagonal load or a top module mounted slightly out of position.
Eight Load Cases That Belong in the Structural Requirements
Static Nominal and Maximum Payload
Test both the normal production load and maximum permitted load. Include base, battery, top module, fixture, carrier and payload in gross mass. Define load support points instead of applying one convenient uniform pressure.
Maximum CG Offset and Overhang
An offset mass creates a static moment M = W × e, where e is the horizontal offset. Overhang can add local bending even when the total mass is unchanged. Test the maximum approved offset in both axes and account for placement tolerance.
Acceleration and Loaded Braking
Use the measured or limited acceleration profiles of the configured robot. The load restraint and module mounts must transmit inertia while wheel reactions shift. Protective stopping and emergency behavior should be treated according to the system's actual safety design, not represented by an arbitrary universal deceleration.
Turning and Combined Braking
Turning creates lateral force and roll moment. A stop initiated while curving combines longitudinal and lateral demand. The relevant case is the permitted speed at the route curvature, with the approved load and floor condition.
Ramp, Cross-Slope and Transition
A grade resolves gravity into components normal and parallel to the floor. A cross-slope shifts lateral reactions. The transition into or out of a ramp can temporarily place wheels on different planes, adding frame torsion.
Joint, Step and Debris Impact
A sharp floor feature can create a short-duration wheel input that exceeds the static reaction. Tire compliance, suspension, speed, wheel diameter and obstacle shape determine the response. A generic dynamic factor should not replace route measurement when the application is critical.
Partial Transfer and Jam
During mobile robot load transfer, the robot and station may share the payload. The support boundary moves as rollers, forks or a lift engage. A jam can apply actuator force without payload motion. Analyze beginning, middle and end positions as separate configurations.
Fault, Recovery and Manual Handling
Consider a failed lift, one disengaged locator, a restrained wheel, a recovery tow point, manual jacking and maintenance support. Recovery loads enter at different places from production loads and can damage a frame that is otherwise adequate.
A Worked Screening Example: Same Gross Mass, Different Structural Demand
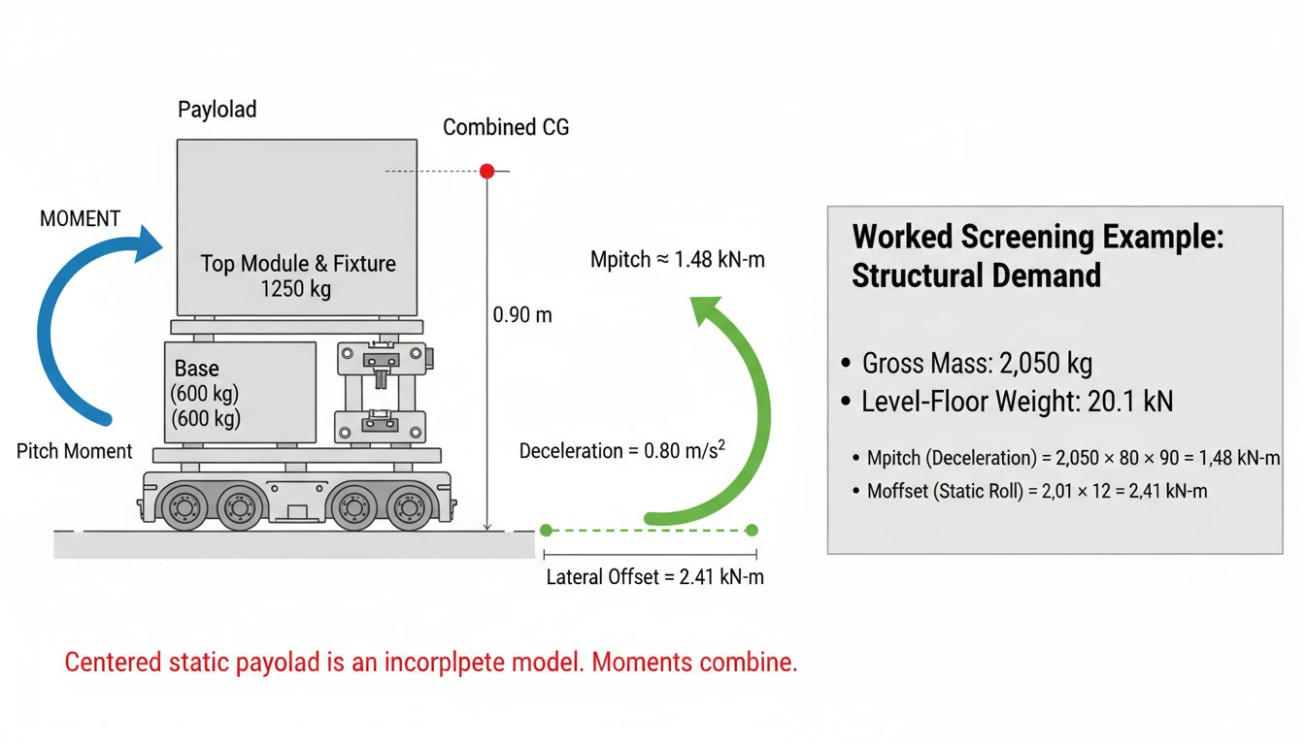
Consider an illustrative configured vehicle comprising a 600 kg base, 250 kg top module and fixture, and 1,200 kg payload. Gross mass is 2,050 kg, giving a level-floor weight of approximately 20.1 kN using g = 9.81 m/s².
If the combined CG is 0.90 m above the floor and controlled deceleration reaches 0.80 m/s², the inertial pitch moment screened at the CG is:
Mpitch ≈ 2,050 × 0.80 × 0.90 = 1.48 kN·m.
If the same configuration also has a 0.12 m lateral CG offset, gravity creates a static roll moment of:
Moffset ≈ 20.1 × 0.12 = 2.41 kN·m.
Those two numbers do not prove safety or provide final wheel loads. They show why a centered static payload is an incomplete model. The moments must be resolved through the actual track width, wheelbase, support compliance, restraint geometry and frame. If the vehicle enters a cross-slope or turns while decelerating, the demands combine rather than occur in isolation.
Now change only the fixture: add two 100 mm spacers below the payload and move the locating pins 80 mm to one side. Gross mass may barely change, but CG height, offset, bolt-group moment and local plate bending all change. A procurement record that lists only “1,200 kg payload” cannot distinguish the two configurations. A load-path record can.
Strength, Stiffness, Fatigue and Joint Integrity Are Separate Decisions
Strength: Will a Part Yield, Buckle or Fracture?
Strength checks compare stresses and loads with material, weld, fastener, bearing and component allowables under defined cases. The load model must include local contacts and direction. A frame can pass a global stress review while a wheel-mount plate, weld throat or threaded insert remains critical.
Stiffness: Will Geometry Stay Functional?
AMR chassis deflection can degrade docking height, conveyor alignment, fork entry, scanner alignment, wheel contact and top-module repeatability long before material yield. The allowable displacement should therefore come from function. A 2026 peer-reviewed heavy-load AGV structural study explicitly related chassis stiffness to docking engagement and evaluated full, eccentric, braking, gradient and transfer cases. The transferable lesson is not its project-specific numbers; it is that deflection acceptance must be connected to an interface requirement.
Fatigue: Will Repeated Cycles Accumulate Damage?
Static proof shows that a structure survived one event. Production durability depends on stress range, mean stress, weld detail, surface condition, residual stress and the number and sequence of cycles. A route with thousands of small joint impacts may govern fatigue even if the maximum payload event is rare.
AMR frame fatigue testing should reproduce the relevant force history, not simply hold dead weight for several hours. Define annual missions, turns, stops, transfers, ramp passages and floor-feature crossings. Instrument likely hot spots, monitor stiffness or alignment drift, inspect welds and fasteners, and perform teardown when appropriate.
Joint Integrity: Will the Path Remain Closed?
A bolted interface may remain below ultimate strength but lose preload, slip, fret or loosen. A welded frame may retain static capacity while cracks initiate at a toe. A bearing mount may develop clearance that changes load sharing. Inspection and maintenance criteria must therefore preserve the load path over time.
Top Modules Re-route Forces, Not Just Payloads
| Module type | Distinct force-flow issue | Evidence to request |
|---|---|---|
| Lift deck | Load migrates through lift pads; offset pickup can rack the mechanism | Pad reactions, actuator and guide loads, mechanical retention, lowered and raised cases |
| Roller conveyor | Transfer thrust and snag force act horizontally above the base | Drive/roller torque limits, jam case, side guides, docking alignment and mount reactions |
| Fork mechanism | Cantilever bending changes continuously with insertion and withdrawal | Fork deflection, carriage reactions, pallet condition limits and partial-engagement case |
| Rack lift | Small contact pads carry the rack; pickup tolerance changes CG and corner loads | Rack geometry, pad pressure, anti-drop feature and mis-pick detection |
| Tow hitch | Drawbar force enters away from the main payload deck and changes during turns | Longitudinal, lateral and vertical hitch loads, articulation limits and recovery case |
| Robot arm | Arm motion creates time-varying base moments and can excite frame modes | Pose-dependent wrench envelope, duty cycle, base stiffness and synchronized motion limits |
A commercial module rating is only a starting point. The base supplier, module builder and integrator must agree on the interface loads and limits. KUKA's official KMP 1500P information, for example, presents the lift and treated hole-grid plate as configuration features alongside payload and loaded speed—not as an independent universal fixture approval. That is the correct systems boundary: the finished application still needs its own configured evidence.
The Load-Path Ledger: A Configuration Record Procurement Can Audit
The original Load-Path Ledger below converts mechanical reasoning into a document that design, procurement, integration, maintenance and operations can share. Each row is an interface with one accountable owner and one evidence package.
| Boundary | Declared inputs | Acceptance evidence | Change trigger |
|---|---|---|---|
| Payload ↔ carrier | Mass, CG, contacts, restraint, tolerance | Drawing, weight/CG record, placement test | New SKU, packaging or stacking pattern |
| Carrier ↔ module | Support and restraint forces | Load-case calculation and transfer test | New pallet, locator, clamp or surface |
| Module ↔ base | Six-axis interface load envelope | Joint drawing, torque/preload record, slip or proof test | Adapter, fastener, spacer or mounting change |
| Base frame | Static, dynamic, impact and fatigue cases | Hand checks, correlated FEA, strain and deflection data | Frame revision, cutout, weld or material change |
| Frame ↔ wheels | Reaction, side force, torque and moment | Component limits, measured corner loads, mount inspection | Wheel, bearing, drive, caster or suspension revision |
| Wheels ↔ floor | Contact load, friction, joint/step and slope | Route survey, floor capacity review and loaded test | Route, coating, floor repair or contamination change |
The ledger prevents a familiar project failure: every supplier proves its own component while no one proves the chain. It also makes change control practical. A taller carrier affects the first rows; a different wheel affects the final rows; a faster motion profile changes dynamic inputs across nearly all of them.
How to Use FEA Without Creating False Confidence

AGV structural analysis is valuable when it represents the real load cases and is correlated with measurement. It becomes misleading when a detailed color plot conceals poor assumptions.
Model the Actual Supports
Fixing the entire underside of the chassis makes the frame artificially stiff. Constraints should represent wheel-mount or suspension interfaces appropriate to the load case. If wheel contact can be lost or support compliance matters, the model may require springs, contacts or a multibody/system representation.
Apply Loads Where They Enter
Use contact pads, rails, bolt groups, actuator attachments and restraint points. A single remote mass at the geometric center can hide local bending. Model eccentric and partial-transfer positions explicitly.
Separate Global and Local Models
A global frame model identifies member forces and torsion. A local submodel can resolve a wheel bracket, weld region or bolt group. Trying to capture every thread in the global model wastes effort, while using only beam elements can miss plate bending. The model hierarchy should follow the questions being asked.
Check Mesh, Contacts and Sensitivity
Report convergence in critical outputs, not only element count. Test how results change with support stiffness, friction, bolt preload and payload position. If a small assumption change reverses the conclusion, the design has not demonstrated a robust margin.
Correlate Against the Configured Machine
Measure wheel reactions, strains and deflections at chosen cases. Compare slopes and distributions, not just one peak number. Update the model when the physical structure behaves differently. A correlated model can support future controlled changes; an uncorrelated model is a hypothesis.
An Evidence Ladder from Drawing to Production Route
- Freeze the configuration. Record base serial/revision, battery, wheels, software motion version, module, adapter, fasteners, fixture, carrier and payload family.
- Build the load-case matrix. Include nominal, maximum, offset, braking, turning, slope, joint, transfer, fault and recovery states.
- Draw free-body diagrams. Identify force entry, reaction, lever arms and restraint for each case.
- Perform screening calculations. Check equilibrium, moments, joint loads, member demand, wheel reactions and component limits.
- Analyze critical structure. Use appropriate FEA or multibody models, sensitivity studies and documented assumptions.
- Measure the physical system. Use wheel scales or load cells, strain gauges, displacement sensors, accelerometers and synchronized event data.
- Run route and transfer tests. Exercise worst permitted floor features, curves, ramps, docking and partial-transfer states with the real load family.
- Run endurance and inspect. Reproduce the representative duty spectrum, trend alignment or stiffness and inspect joints and hot spots.
- Control lifecycle changes. Reassess when payload, fixture, wheel, speed, route, floor or software changes.
This ladder complements the site's heavy-payload AMR buying and acceptance guide. The buying guide defines what the project should specify and accept; the ladder above defines the mechanical evidence needed to show that forces reach the floor without breaking the functional envelope.
Standards Define Responsibilities, Not a Universal Chassis Margin
ISO 3691-4:2023 covers safety requirements and verification for driverless industrial trucks and explicitly includes AGVs and AMRs as examples. Its public scope also states that operating-zone condition significantly affects safe operation. This supports a route-specific view of floor, slope and interaction conditions, but it should not be misrepresented as providing a universal payload factor, chassis deflection limit or docking-success percentage.
The current ANSI/A3 R15.08 series separates responsibilities across the industrial mobile robot, system/application integration and day-to-day use. That lifecycle division fits the Load-Path Ledger: manufacturers declare base limits, integrators prove the configured application, and users maintain approved conditions and manage changes.
Neither standards citation replaces the applicable conformity assessment, risk assessment, manufacturer instructions or local legal requirements. The engineering team must derive acceptance limits from the actual application and document the basis.
Procurement Questions That Expose a Weak Load Path

- What payload contact geometry was used to establish the rating?
- What combined CG height and offsets are permitted for the configured vehicle?
- What six-axis loads may enter through the module mounting interface?
- Which fasteners, dowels or shear features close the horizontal force path?
- What are the maximum allowable wheel reactions, side loads and mount moments?
- How were floor unevenness, joint impact, slope and cross-slope represented?
- What deflection limit protects docking, transfer, sensing and wheel contact?
- Which fatigue spectrum represents the intended annual duty cycle?
- Which calculations or models were correlated with physical measurements?
- Which changes require review, restricted operation or revalidation?
A supplier that can answer these questions is describing an engineering envelope. A supplier that returns only to nominal kilograms is describing a catalog line. Buyers who still need to establish the wider application boundary can start with the internal heavy-payload chassis engineering overview and the heavy-payload AMR safety and risk-assessment guide.
Focused FAQ
What is a load path in a heavy-payload AMR?
It is the continuous route by which gravity, inertia, transfer forces and floor reactions pass through the payload, carrier, top module, mounting interface, chassis, wheel assemblies and floor. It changes with the operating event, so static travel, braking, turning, floor impact and transfer need separate force-flow diagrams.
Why can two loads with the same mass produce different frame demand?
Support location, CG height, lateral or longitudinal offset, restraint geometry and overhang change the forces and moments entering the structure. A compact centered load may distribute force across several members, while a tall offset load can increase wheel-load transfer, bolt-group moment and local plate bending at the same mass.
Can I calculate each wheel load by dividing gross mass by the number of wheels?
Only as a rough starting point under ideal symmetric conditions. Real corner loads depend on CG position, wheelbase, track width, chassis torsional stiffness, suspension and tire compliance, floor flatness, slope and acceleration. Use equilibrium-based screening, a suitable compliance model and physical wheel-reaction measurements.
What is the difference between chassis strength and chassis stiffness?
Strength concerns yielding, buckling or fracture. Stiffness concerns displacement and rotation under load. A frame can remain below yield yet deflect enough to lose docking alignment, change wheel contact, disturb sensors or make a transfer mechanism bind. Both need application-derived acceptance limits.
Why is partial load transfer often a critical case?
When a payload is moving between a station and the robot, support points and reactions migrate. The robot may carry an eccentric fraction of the load while an actuator applies horizontal force. A snag or jam can add force without motion. These transient geometries may create higher local demand than a fully seated payload.
What evidence should a buyer request for a custom top module?
Request the supported payload/CG envelope, interface load envelope, mounting drawing and joint specification, static and dynamic load cases, deflection limits, fatigue basis, FEA assumptions, physical test results, route/transfer acceptance data and change-control triggers. Evidence should identify the exact configured base, module, fixture and software motion limits.
When should the load path be revalidated?
Revalidation should be considered after changes to payload family, stacking, carrier, fixture, adapter, fasteners, top module, wheel, suspension, frame, speed or acceleration profile, route, ramp, floor coating, joint condition or recovery procedure. The scope can be targeted, but it should be based on which ledger boundaries changed.
Conclusion: Approve the Force Chain, Not the Payload Label
The defining mechanical question for a heavy mobile robot is not merely how many kilograms it can hold. It is whether every relevant force has a known, continuous and durable route from the load to the floor—and back from the floor to the load when the robot accelerates, brakes or turns.
A reliable design begins with real payload contacts, separates support from restraint, treats the top-module mounting pattern as a structural interface, carries loads through deliberate frame members, resolves reactions at wheel assemblies and includes the production floor in the model. It tests nominal and worst-case configurations, controls deflection as well as stress, builds fatigue from the real duty spectrum and preserves joint integrity through maintenance.
The Force-Flow Map makes operating events visible. The Load-Path Ledger assigns evidence and ownership at each boundary. Together they convert a catalog payload rating into an auditable mechanical case. That is the standard of proof required when a chassis is expected to move heavy, valuable or safety-relevant loads for thousands of production cycles rather than complete one convincing demonstration.
#HeavyPayloadAMR #AMRLoadPath #AMRChassisDesign #AGVFrameDesign #AMRLoadDistribution #AGVWheelLoads #AMRTopModule #ChassisDeflection #StructuralAnalysis #MobileRobotEngineering #StructuralFatigue #LoadPathValidation

