Can Autonomous Forklifts Load and Unload Trailers Without Human Help?
The question behind the latest autonomous forklift announcements
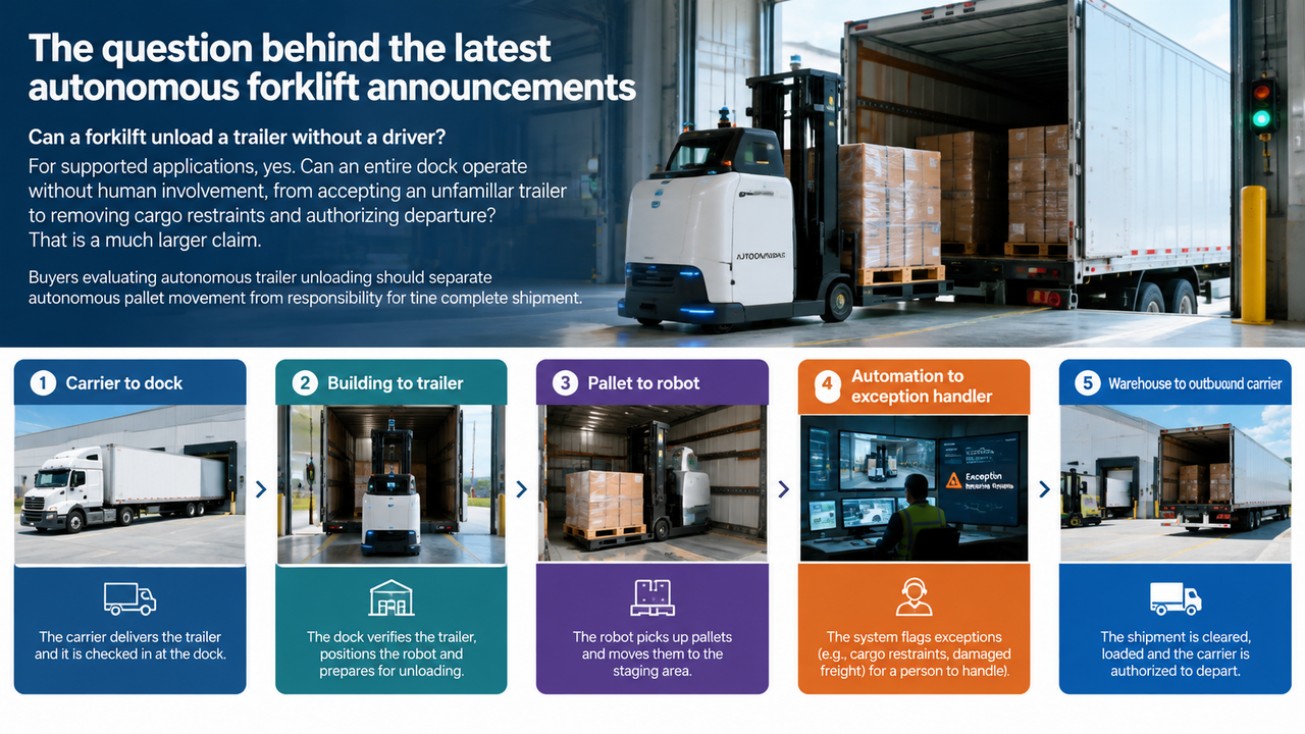
Can a forklift unload a trailer without a driver? For supported applications, yes. Can an entire dock operate without human involvement, from accepting an unfamiliar trailer to removing cargo restraints and authorizing departure? That is a much larger claim. Buyers evaluating autonomous trailer unloading should separate autonomous pallet movement from responsibility for the complete shipment.
That distinction has become particularly relevant in late 2026. Recent announcements from Gideon, KION, Toyota Industries and Hyundai WIA put truck and trailer handling firmly on the industrial automation agenda. However, the announcements describe different vehicle configurations, deployment stages and operating boundaries. A commercial product, a completed proof of concept and a future factory deployment are useful evidence of industry activity, but they are not interchangeable evidence of production readiness at your dock.
This analysis follows a shipment through five handovers: carrier to dock, building to trailer, pallet to robot, automation to exception handler, and warehouse to outbound carrier. The purpose is to help distribution leaders, plant engineers, third-party logistics operators and procurement teams identify what they would actually be buying. The central question is where the robot's responsibility ends and who owns the next action.
What changed: four recent developments, four different evidence levels
The following timeline is current as of October 9, 2026. It records supplier disclosures rather than independently audited performance results. Publication dates are distinguished from the dates when trials or deployments occurred or are expected to occur.
| Publication date | Development | What a buyer can reasonably conclude |
|---|---|---|
| October 7, 2026 | Gideon announced expanded Trey capabilities and described commercial availability in North America. | Commercial evaluation is possible for supported applications. The announcement also describes human participation in handling dunnage. |
| September 7, 2026 | Hyundai WIA outlined autonomous logistics technology, including truck loading and unloading, with first deployment planned at Kia Autoland Hwaseong in May 2027. | This is a forward deployment plan. It is not evidence that the announced application was already in production when the release appeared. |
| September 1, 2026 | Toyota Industries and Suntory Logistics announced a truck-handling trial scheduled to begin in November 2026, targeting operational introduction from September 2028 onward. | A structured trial is planned. Its truck configuration and application scope must be distinguished from rear-entry trailer operations. |
| August 27, 2026 | KION reported a trailer-handling proof of concept at Colruyt completed earlier in 2026. | The proof of concept is relevant; the same article's established pallet-transport fleet should not be counted as a production trailer-loading fleet. |
These four disclosures make this an active news topic. They do not establish global search volume or prove that every trailer type can be automated. Earlier commercial development also matters: Fox Robotics introduced trailer-loading functionality with its Mk3 announcement in March 2025. The current discussion is therefore about widening operational scope and making deployments repeatable, rather than the sudden invention of driverless pallet handling.
For procurement, the useful response is to ask a narrower question than whether the technology exists. Which incoming shipments can this particular system handle, at this particular building, with an acceptable amount of intervention? A credible answer connects the supplier's supported application to the buyer's actual freight mix.
Define the job before comparing machines
The phrase automated truck unloading can describe substantially different equipment. An autonomous forklift entering a trailer to retrieve pallets has a different task from a robotic arm handling loose cartons. A fixed transfer system serving specially equipped trailers has another operating model. Treating these as one product category produces misleading comparisons of throughput, infrastructure cost and carrier compatibility.
Start with the unit of handling. Is it a stable palletized load, an individual carton, a roll cage or a unit that requires a special attachment? Next define access: rear entry, side access or a dedicated transfer interface. Finally, define the endpoint. Moving a pallet out of the trailer is different from identifying it, booking its receipt and delivering it to a usable warehouse location.
The rest of this article focuses on pallet-handling forklifts crossing a loading-dock interface. The procurement recommendations are an analytical framework, not a claim that every named supplier offers every capability discussed. Systems should be compared against the same declared job, including exclusions.
A useful scope statement might read: receive approved palletized shipments from a defined trailer population, move accepted loads to assigned receiving positions, report exceptions, and maintain traceable task status. That statement leaves room to measure automation honestly. It does not quietly assume that inspection, cargo-restraint removal or shipment reconciliation has disappeared.
Handover one: the carrier brings variability to the dock

Approve the arriving trailer, not just the carrier account
A carrier may send equipment with different interior dimensions, floor construction, rear thresholds or maintenance histories. An approved carrier name therefore does not establish that a particular arrival belongs inside the robot's operating envelope. The first handover is an eligibility decision: is this actual trailer suitable for the assigned automated process today?
For a buyer, a trailer eligibility record should connect an equipment identifier with the relevant configuration and current inspection result. A previously accepted model still requires condition checks. A floor repair, loose debris or a changed internal arrangement can matter even when the appointment and purchase order are correct. Receiving teams need a clear route for an ineligible arrival so that commercial pressure does not become an informal engineering approval.
U.S. OSHA's powered industrial truck requirements address checking trailer floors for damage or weakness before entry and identify support considerations for uncoupled semitrailers. These are U.S. requirements, not a universal certification of an autonomous application. Their relevance here is the physical interface: removing the onboard driver does not remove the need to evaluate the structure being entered.
A dock appointment is not permission to move
The control design must distinguish administrative readiness from physical readiness. An appointment can be checked in while a trailer is still being positioned. A warehouse task can exist while the dock is unavailable. The buyer should require the integrator to explain how these conditions are represented, who may change them and what prevents stale information from authorizing movement.
The trailer restraint system belongs in that discussion. Its compatibility with the arriving equipment, its verified state and the response to a lost or contradictory signal need to be addressed in the site design. An illuminated dock signal, a network message and a safety-related permission are not automatically equivalent.
Rite-Hite distinguishes trailer creep, premature departure and support-related failures as different dock hazards. That distinction helps explain why one device or one dashboard status cannot be assumed to solve the complete interface. The appropriate restraint, support and communication arrangements require site-specific evaluation.
Contractually, this handover needs a named owner. The carrier supplies equipment information, site operations accepts the arrival, engineering defines the permissible conditions, and the integration design establishes the movement permissions. Unassigned responsibility usually becomes unplanned operator work during the pilot.
Handover two: the robot crosses from a building into a vehicle

The payload rating is only one number
A robot capable of lifting the pallet is not automatically suitable for the path underneath it. Evaluating dock leveler capacity requires the loaded machine and the way its wheels apply force, not just the weight of the goods. The purchasing specification should connect the robot configuration to the actual leveler model and duty cycle.
Blue Giant's capacity-selection guidance includes forklift weight with battery, attachments, pallet weight, wheel arrangement, speed and usage frequency. It also notes that manufacturers use different capacity terminology. Consequently, two similarly numbered ratings should not be treated as directly comparable without understanding their definitions.
Ask for an engineering assessment covering the proposed battery, attachments and load envelope. Gross mass alone does not describe every local loading condition; wheel and axle loading, contact geometry and transitions can affect the assessment. The required evidence is compatibility with the identified infrastructure under the intended operation, rather than a spreadsheet showing that the pallet weighs less than a large number on a brochure.
A ramp gradient does not describe the whole crossing
Useful autonomous forklift dock requirements identify more than a maximum slope. The transition onto the leveler, the transition into the trailer, underbody clearance, available width and the loaded vehicle's travel configuration all belong in the evaluation. A vehicle might negotiate a steady incline yet encounter a clearance problem where that incline begins or ends.
Blue Giant's dimensional guidance links leveler length to dock-to-truck height differences and equipment under-clearance, and directs users to the handling-equipment manufacturer for grade capability. It also identifies rear-interface geometry as relevant to lip projection. Those considerations support measuring the actual crossing instead of assuming that an existing dock plate proves compatibility.
The site assessment should cover the expected height range during the entire shipment. Conditions at the first pallet may not match conditions at the last. Hyundai WIA's announcement specifically discusses changing truck-bed height as loading progresses, illustrating why vehicle geometry is a moving boundary rather than a single commissioning measurement.
The floor inside the trailer needs its own approval
Checking trailer floor capacity is a separate task from checking the leveler. Trailer road-load ratings do not, by themselves, establish suitability for a particular forklift wheel-loading pattern. The trailer manufacturer or other responsible engineering authority should confirm the applicable floor rating and its conditions.
Great Dane describes different refrigerated-trailer floor designs with different stated rating conventions. The practical lesson is that “reefer floor” is not a complete structural specification. Nor does successful operation in a dry trailer validate every refrigerated application, where surface profile, temperature and moisture conditions may differ.
For broader background, review our guide to loaded-vehicle floor and ramp requirements. The dock-specific task is to apply that thinking across a temporary connection between two structures, with both current condition and expected variation recorded.
Handover three: a visible pallet becomes an accepted load

Finding a pallet does not establish that it can be retrieved safely or that it is the pallet the warehouse should receive. The robot's perception, the load's physical condition and the shipment's business identity are separate acceptance questions. This distinction becomes especially valuable when evaluating demonstrations that show smooth motion but provide little information about rejected freight.
The physical envelope should describe pallet dimensions, fork-pocket access, expected orientation, load height, overhang and acceptable condition. Buyers should request both a supported-load list and an excluded-load list. The second list can reveal more about deployment effort than a broad claim of flexible vision.
Consider an original hypothetical example: a pallet is geometrically recognizable, but loose wrapping obscures an entry pocket. Another pallet has clear pockets but carries a visibly shifted load. A third is physically suitable yet belongs to a different shipment. These should not collapse into the same generic “pick failed” event. They require different owners, recovery actions and upstream improvements.
Our earlier discussion of pallet detection and pickup eligibility explains this boundary in more detail. At the dock, the additional issue is contractual: who is responsible for identifying freight that is outside the agreed handling envelope, and how is that event charged or recorded?
The receiving position is part of the job
A pallet cleared from the trailer still needs somewhere appropriate to go. If staging is full, downstream inspection is delayed or a receiving location is blocked, the robot's successful pickup does not create completed warehouse capacity. The interface should define what happens when the destination becomes unavailable after the task has started.
The warehouse management system also needs a reliable definition of receipt. Does physical placement trigger an inventory transaction, or does a separate check release the stock? What happens if the placement succeeds but the acknowledgement is lost? The integration specification should make duplicate tasks and missing confirmations visible rather than allowing a physical load and its digital record to drift apart.
Environmental changes belong in this evaluation too. A dock route may cross contrasting lighting conditions or encounter contaminated sensors. These should be tested within the supplier's supported environment, using the principles in our environmental sensor validation guide. A successful run under one lighting condition is useful evidence, but it does not establish the entire operating envelope.
Handover four: exceptions reveal how autonomous the process really is

The most revealing question in a supplier meeting is often simple: show what happens when the system cannot continue. For loading dock automation, exception handling determines whether a small interruption stays local or blocks a door while several teams decide who owns it.
Gideon's October announcement offers a concrete example of the boundary. It describes detecting dunnage and notifying an associate to remove it; where material must be added during loading, the robot pauses outside the trailer while a person completes the task and confirms continuation. That is useful automation with an explicit human handover, not evidence that every activity inside a shipment is unattended.
The buyer should translate each expected exception into a service workflow: detection, notification, acknowledgement, authorized intervention, confirmation and controlled resumption. The responsible person must know what condition caused the pause and what evidence is needed before work resumes. “Call the operator” is incomplete if the operator is serving another area or lacks the required authority.
Count the waiting, not only the intervention
A two-minute physical correction can create a much longer delay if it takes several minutes to reach the qualified responder. Staffing assumptions should therefore include response time and concurrent demand. One person supporting multiple doors may work well under one freight mix and become the bottleneck when several atypical arrivals occur together.
Keep business exceptions separate from protective stops. A missing inventory identifier, a damaged pallet and a safety-related interruption should not share an undifferentiated recovery button. Access and restart procedures must follow the approved application design; production targets must not encourage people to bypass protective functions or enter an active operating area.
Our guide to application-specific risk assessment provides a foundation for assigning those responsibilities. The useful commercial outcome is a known support model: who responds, what training is required, when vendor assistance is needed and how the operation continues when the automated route is unavailable.
Handover five: loading a trailer creates a shipment, not just empty floor space

Buyers should not assume that proving unloading automatically proves outbound loading. Inbound work starts with an arrangement created elsewhere. Outbound work must create an arrangement that satisfies the shipper's plan and can be accepted for transport. These are related capabilities, but their business logic differs.
A valid pallet loading pattern needs more than an attractive utilization percentage. The plan may have to account for delivery sequence, pallet dimensions, product compatibility, load stability and the applicable transport-loading constraints. The robotic system's ability to place a load does not establish that the shipment plan has been approved by the responsible transport function.
For autonomous forklift trailer loading, define where the approved plan originates and how changes are handled. If a planned pallet is unavailable or rejected, does the system wait, select an authorized substitute or request a revised plan? An improvised placement that preserves robot utilization could create a downstream delivery problem.
Define completion at two levels. A movement is complete when the agreed physical and digital confirmations have occurred. A shipment is complete when all required quantities, exceptions, cargo-securing tasks and release checks have been reconciled. Treating the last pallet movement as automatic permission for departure leaves a gap between robotics and transport operations.
The release decision should therefore have a named owner and a visible record. For a third-party logistics provider, the contract should also state whether customer-specific packing or loading instructions are part of the automated scope. Without that boundary, customized service work can reappear as unpriced manual labor after the automation investment has been approved.
The commercial calculation: measure occupied-door time
Pallets per hour can be a useful equipment metric, provided its measurement boundary is stated. It is not automatically a measure of trailer turnaround, labor saving or warehouse throughput. A buyer should ask whether the clock includes preparation, travel to staging, waiting, intervention and shipment closeout.
Consider the following original planning example. The numbers are hypothetical and are not a performance claim for any supplier. A trailer contains 24 pallets. During active handling, a robot averages 30 pallets per hour, including the defined movement between trailer and receiving position. That portion of the job takes 48 minutes.
| Activity | Elapsed time | Accounting boundary |
|---|---|---|
| Dock preparation and release to automation | 12 minutes | Occurs before the first automated movement |
| Handling 24 pallets at 30 pallets per hour | 48 minutes | Active handling time; not a labor-hours figure |
| Additional waiting and intervention | 8 minutes | Excluded from the active handling figure |
| Final reconciliation and closeout | 7 minutes | After handling, before the door is available again |
| Total occupied-door time | 75 minutes | Sum of these sequential activities |
The resulting door-level throughput is 24 divided by 1.25 hours, or 19.2 pallets per hour. If the active handling rate increases to 40 pallets per hour while all other times stay unchanged, total occupation falls to 63 minutes and throughput becomes approximately 22.9 pallets per hour. A one-third increase in the equipment's active rate produces about a 19% improvement in this end-to-end measure.
This example assumes no overlap. A real study should use timestamps to identify parallel activities and avoid double counting. It should also distinguish time occupying the physical door from yard waiting time and total time on site. Each measure answers a different operational question.
Labor needs its own ledger. Forty-eight minutes of autonomous operation does not prove that forty-eight paid minutes have been removed from a shift. Record attendance, supervision, exception response and support work, then determine whether people can be productively reassigned. Include recurring software, maintenance and infrastructure costs in the business case. Our fleet capacity and peak-demand planning guide is relevant when several doors share robots or receiving space.
A pilot should explain the difficult arrivals
A useful pilot samples the operation the buyer intends to automate. If the future contract includes several trailer families, pallet conditions and shifts, a demonstration using one ideal shipment cannot establish the full scope. Begin with a documented baseline and identify which cases are being included, excluded or deferred.
The selection method matters. Letting a supplier choose only suitable arrivals measures performance on a screened population. That can be appropriate for an initial technical exercise, but the screening effort and the rejected share must remain visible in the commercial analysis. Otherwise, the business case assumes an automation coverage that the test never measured.
Use separate denominators. Shipment eligibility is the number of arrivals meeting the agreed scope divided by all arrivals considered. Autonomous task completion concerns tasks inside that approved scope. Overall operational coverage concerns the fraction of actual work automated across the full population. A high completion rate within a narrow eligible group does not establish high coverage of the building.
Record the reason for each rejection or intervention, not merely its count. A trailer-interface incompatibility suggests different action from missing shipment data. A recurring pallet-quality issue might justify supplier packaging changes. Slow responder arrival suggests a support problem. Buying another robot will not necessarily improve any of those causes.
Acceptance criteria should connect safety, throughput, damage, inventory accuracy and support requirements. The project needs agreed evidence for the selected application, not an arbitrary industry-wide pass rate invented for the proposal. Use our site acceptance evidence framework to organize the records, while keeping the dock-specific trailer and shipment conditions explicit.
After release, preserve the operating assumptions. A new carrier contract, trailer model, pallet supplier or loading arrangement can change the mix that was validated. Operations should know which changes require engineering review and which remain within the accepted envelope. Expansion becomes more predictable when each new door inherits a clear specification instead of an undocumented collection of pilot adjustments.
Focused FAQ
Can autonomous forklifts unload trucks without human help?
They can perform pallet movements without an onboard driver in supported applications. Whether a complete arrival can be handled without assistance depends on its condition, cargo restraints, inspection requirements, system interfaces and exception workflow. Ask suppliers to show the human tasks that remain and to measure their frequency and response time during representative operation.
Can an existing loading dock be used?
Possibly, but existing use by a manual forklift does not establish compatibility with a different autonomous machine. The proposed vehicle, loading interface and trailer population need a joint assessment. Structural loading, clearance, sensing conditions, control integration and operating procedures can each affect whether modifications are necessary.
How should a buyer specify dock leveler capacity?
Provide the equipment configuration and operating conditions to the leveler supplier or responsible engineer. Include the loaded vehicle, battery, attachments, relevant wheel-loading information and expected duty. Require confirmation for the actual installation. A robot's rated payload alone is not enough to select or approve the interface.
Is a refrigerated trailer equivalent to a dry van for automation?
No blanket equivalence should be assumed. Floor construction, rear geometry and environmental conditions can differ. Request confirmation for the particular trailer family and temperature range, and include representative operating conditions in validation. A supplier's approved application list is more useful than a general statement that the robot works inside trailers.
Which metric best shows whether the investment is working?
No single metric is sufficient. Compare occupied-door time, operational coverage, damage, inventory accuracy and retained human workload against the baseline. Equipment handling rate helps explain performance, but it cannot replace shipment-level results. Report excluded arrivals and exception time so the apparent improvement is not created by removing difficult work from the measurement.
Should a buyer automate loading and unloading together?
Only if both workflows fit the supported application and business case. Unloading emphasizes acceptance of incoming freight; loading also requires an approved placement plan and shipment release process. A phased deployment can be sensible when one direction has more consistent freight, but its economics should not assume that the second direction is already solved.
Buy the handovers, not only the motion
The strongest reason to investigate this topic now is the growing set of concrete supplier developments. The strongest reason to remain precise is that each development solves a bounded job. A useful purchasing decision connects an eligible trailer, a verified crossing, an acceptable pallet, a staffed exception process and an authorized shipment release.
When those connections are explicit, the buyer can distinguish a promising robot from a repeatable dock operation. The next supplier conversation should therefore start with a real arrival and follow it all the way to a released door. Every unexplained handover is work that somebody will still have to perform.
Sources and evidence boundaries
News information was checked on October 9, 2026. The linked company announcements support their stated development stages; supplier descriptions have not been independently performance-audited here. Engineering recommendations, the handover framework and the numerical planning example are original analysis. Application approval requires the relevant equipment suppliers and competent site engineering personnel. The OSHA reference is specific to the United States.
- Gideon: Trey announcement, October 7, 2026.
- Hyundai WIA: autonomous logistics announcement, September 7, 2026.
- Toyota Industries: joint truck-handling trial announcement, September 1, 2026.
- KION: technology development and Colruyt proof of concept, August 27, 2026.
- Fox Robotics: Mk3 announcement, March 12, 2025.
- Blue Giant: leveler load classification and capacity.
- Blue Giant: leveler dimensions and interface geometry.
- Great Dane: refrigerated-trailer floor designs.
- Rite-Hite: dock separation hazards.
- OSHA: 29 CFR 1910.178, powered industrial trucks.

